

226
6 Hierarchical Component Models
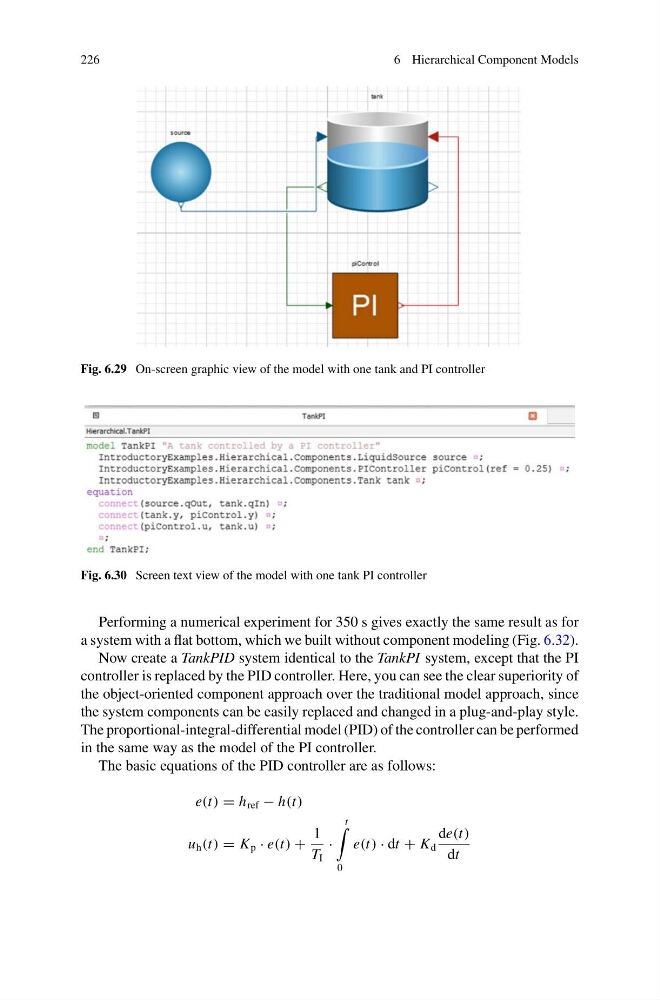
Fig. 6.29 On-screen graphic view of the model with one tank and PI controller
Fig. 6.30 Screen text view of the model with one tank PI controller
Performing a numerical experiment for 350 s gives exactly the same result as for
a system with a flat bottom, which we built without component modeling (Fig. 6.32).
Now create a TankPID system identical to the TankPI system, except that the PI
controller is replaced by the PID controller. Here, you can see the clear superiority of
the object-oriented component approach over the traditional model approach, since
the system components can be easily replaced and changed in a plug-and-play style.
The proportional-integral-differential model (PID) of the controller can be performed
in the same way as the model of the PI controller.
The basic equations of the PID controller are as follows:
e(t) = h ref − h(t)
u h (t) = K p · e(t) +
1
T I
·
t
0
e(t) · dt + K d
de(t)
dt