

124
3 Computer Simulation of Dynamic Systems
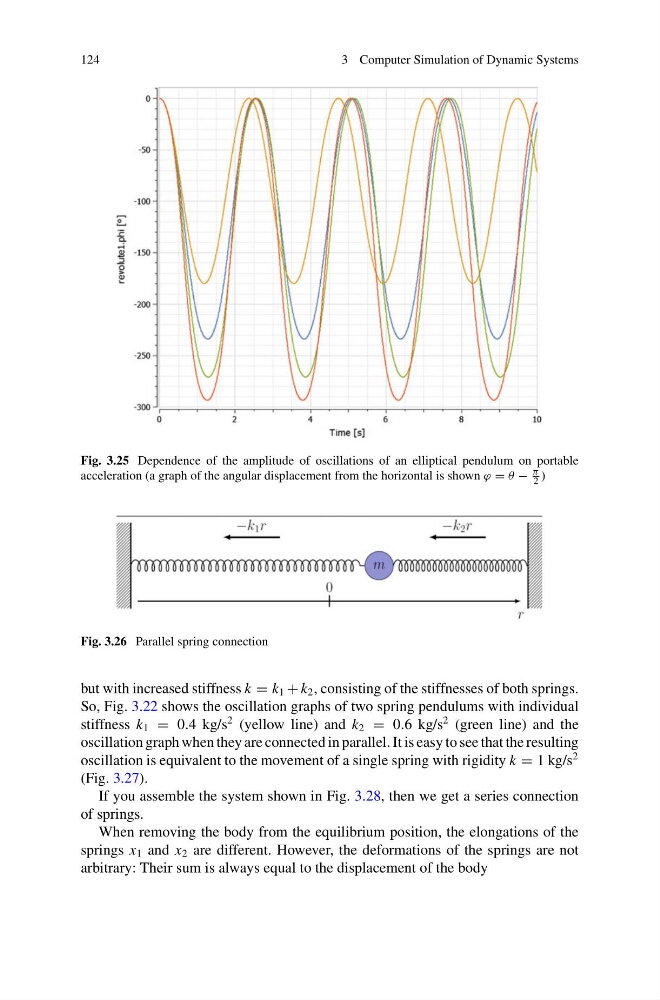
Fig. 3.25 Dependence of the amplitude of oscillations of an elliptical pendulum on portable
acceleration (a graph of the angular displacement from the horizontal is shown ϕ = θ −
π
2 )
Fig. 3.26 Parallel spring connection
but with increased stiffness k = k 1 + k 2 , consisting of the stiffnesses of both springs.
So, Fig. 3.22 shows the oscillation graphs of two spring pendulums with individual
stiffness k 1 = 0.4 kg/s
2 (yellow line) and k 2 = 0.6 kg/s
2 (green line) and the
oscillation graph when they are connected in parallel. It is easy to see that the resulting
oscillation is equivalent to the movement of a single spring with rigidity k = 1 kg/s
2
(Fig. 3.27).
If you assemble the system shown in Fig. 3.28, then we get a series connection
of springs.
When removing the body from the equilibrium position, the elongations of the
springs x 1 and x 2 are different. However, the deformations of the springs are not
arbitrary: Their sum is always equal to the displacement of the body