

118
3 Computer Simulation of Dynamic Systems
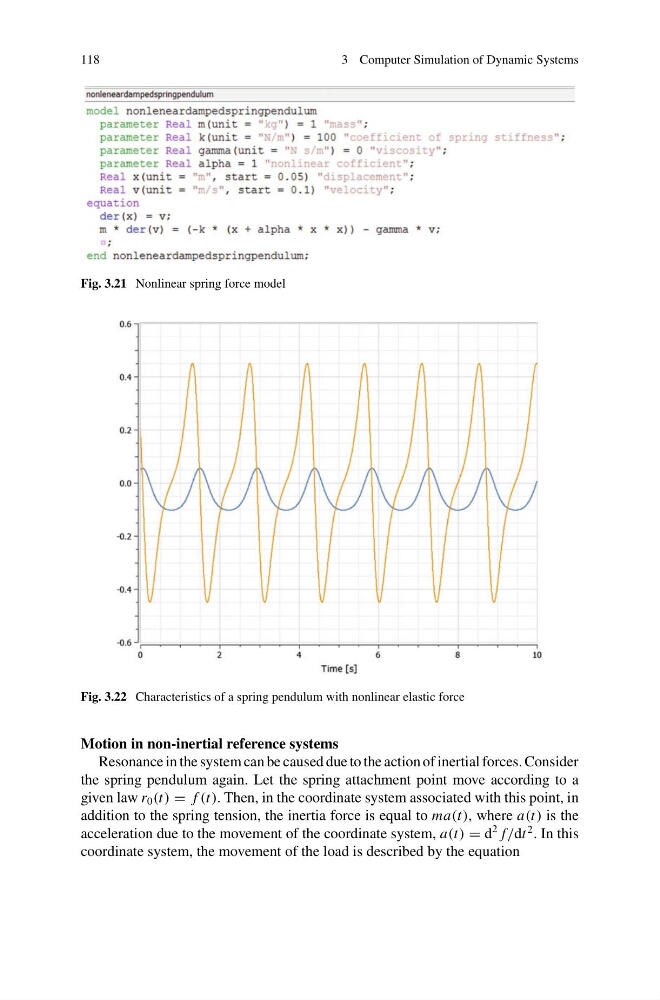
Fig. 3.21 Nonlinear spring force model
Fig. 3.22 Characteristics of a spring pendulum with nonlinear elastic force
Motion in non-inertial reference systems
Resonance in the system can be caused due to the action of inertial forces. Consider
the spring pendulum again. Let the spring attachment point move according to a
given law r 0 (t) = f (t). Then, in the coordinate system associated with this point, in
addition to the spring tension, the inertia force is equal to ma(t), where a(t) is the
acceleration due to the movement of the coordinate system, a(t) = d
2 f /dt
2 . In this
coordinate system, the movement of the load is described by the equation