

588
R. Frühwirth et al.
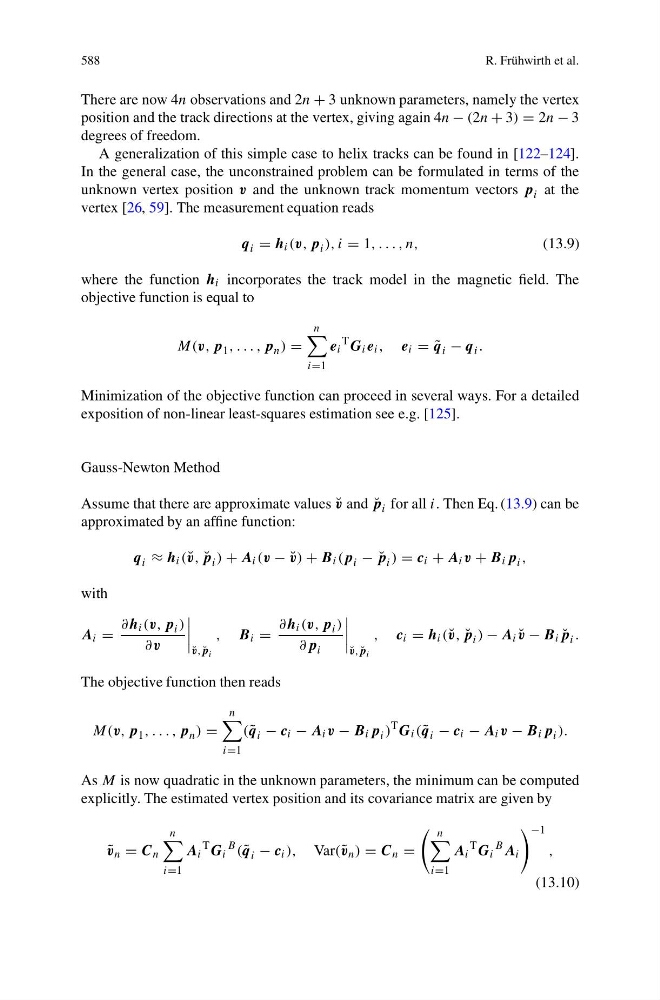
There are now 4n observations and 2n + 3 unknown parameters, namely the vertex
position and the track directions at the vertex, giving again 4n − (2n + 3) = 2n − 3
degrees of freedom.
A generalization of this simple case to helix tracks can be found in [122–124].
In the general case, the unconstrained problem can be formulated in terms of the
unknown vertex position v and the unknown track momentum vectors p i at the
vertex [26, 59]. The measurement equation reads
q i = h i (v, p i ), i = 1, . . . , n,
(13.9)
where the function h i incorporates the track model in the magnetic field. The
objective function is equal to
M(v, p 1 , . . . , p n ) =
n
i=1
e i
T G i e i , e i = ˜
q i − q i .
Minimization of the objective function can proceed in several ways. For a detailed
exposition of non-linear least-squares estimation see e.g. [125].
Gauss-Newton Method
Assume that there are approximate values ˘
v and ˘
p i for all i. Then Eq. (13.9) can be
approximated by an affine function:
q i ≈ h i (˘ v, ˘
p i ) + A i (v − ˘
v) + B i (p i − ˘
p i ) = c i + A i v + B i p i ,
with
A i =
∂h i (v, p i )
∂v
˘
v, ˘
p i
, B i =
∂h i (v, p i )
∂p i
˘
v, ˘
p i
, c i = h i (˘ v, ˘
p i ) − A i ˘
v − B i ˘
p i .
The objective function then reads
M(v, p 1 , . . . , p n ) =
n
i=1
( ˜
q i − c i − A i v − B i p i )
T G i ( ˜
q i − c i − A i v − B i p i ).
As M is now quadratic in the unknown parameters, the minimum can be computed
explicitly. The estimated vertex position and its covariance matrix are given by
˜
v n = C n
n
i=1
A i
T G i
B ( ˜
q i − c i ), Var(˜ v n ) = C n =
n
i=1
A i
T G i
B A i
−1
,
(13.10)