

13 Pattern Recognition and Reconstruction
583
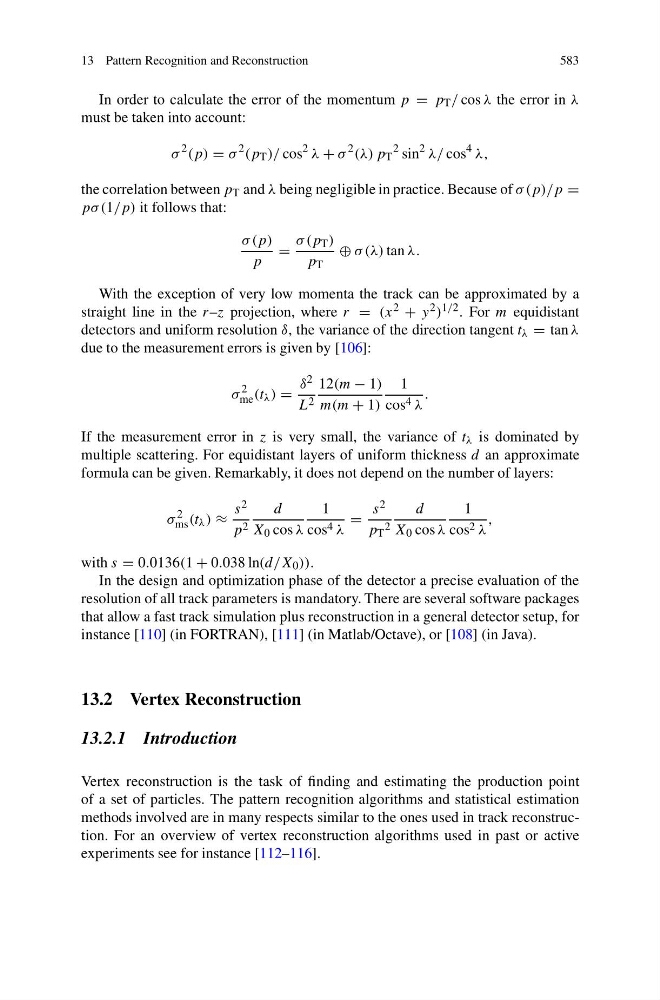
In order to calculate the error of the momentum p = p T / cos λ the error in λ
must be taken into account:
σ
2 (p) = σ
2 (p T )/ cos
2 λ + σ
2 (λ) p T
2 sin
2 λ/ cos
4 λ,
the correlation between p T and λ being negligible in practice. Because of σ (p)/p =
pσ (1/p) it follows that:
σ (p)
p
=
σ (p T )
p T
⊕ σ (λ) tan λ.
With the exception of very low momenta the track can be approximated by a
straight line in the r–z projection, where r = (x 2 + y 2 ) 1/2 . For m equidistant
detectors and uniform resolution δ, the variance of the direction tangent t λ = tan λ
due to the measurement errors is given by [106]:
σ
2
me (t λ ) =
δ 2
L 2
12(m − 1)
m(m + 1)
1
cos 4 λ
.
If the measurement error in z is very small, the variance of t λ is dominated by
multiple scattering. For equidistant layers of uniform thickness d an approximate
formula can be given. Remarkably, it does not depend on the number of layers:
σ
2
ms (t λ ) ≈
s 2
p 2
d
X 0 cos λ
1
cos 4 λ
=
s 2
p T
2
d
X 0 cos λ
1
cos 2 λ
,
with s = 0.0136(1 + 0.038 ln(d/X 0 )).
In the design and optimization phase of the detector a precise evaluation of the
resolution of all track parameters is mandatory. There are several software packages
that allow a fast track simulation plus reconstruction in a general detector setup, for
instance [110] (in FORTRAN), [111] (in Matlab/Octave), or [108] (in Java).
13.2 Vertex Reconstruction
13.2.1 Introduction
Vertex reconstruction is the task of finding and estimating the production point
of a set of particles. The pattern recognition algorithms and statistical estimation
methods involved are in many respects similar to the ones used in track reconstruction. For an overview of vertex reconstruction algorithms used in past or active
experiments see for instance [112–116].