

76
3 Continuum Mechanics and Nonlinear Elasticity
Solution
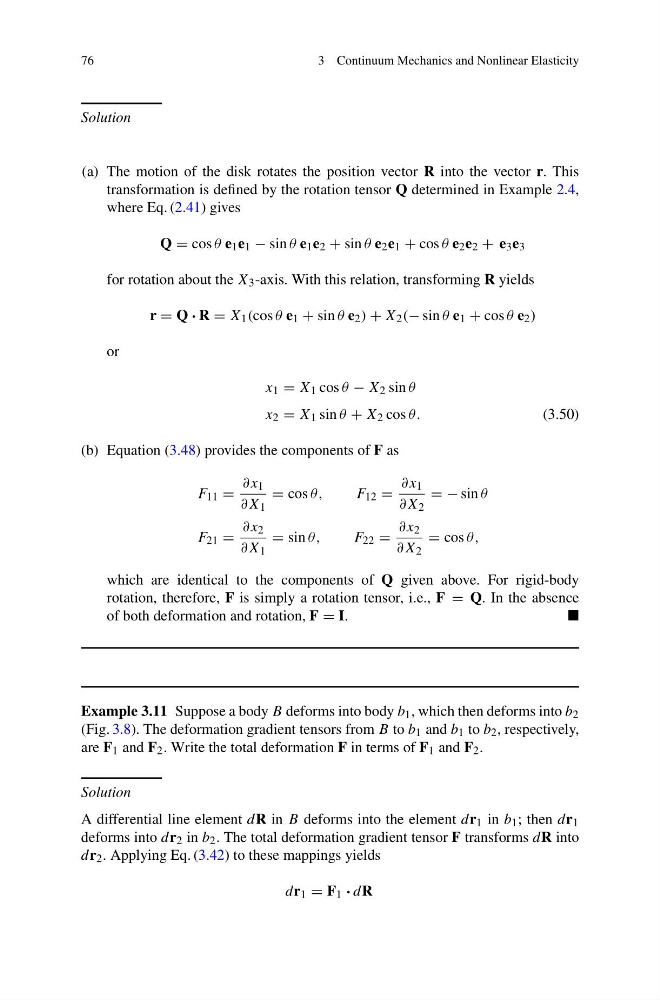
(a) The motion of the disk rotates the position vector R into the vector r. This
transformation is defined by the rotation tensor Q determined in Example 2.4,
where Eq. (2.41) gives
Q = cos θ e 1 e 1 − sin θ e 1 e 2 + sin θ e 2 e 1 + cos θ e 2 e 2 + e 3 e 3
for rotation about the X 3 -axis. With this relation, transforming R yields
r = Q · R = X 1 (cos θ e 1 + sin θ e 2 ) + X 2 (− sin θ e 1 + cos θ e 2 )
or
x 1 = X 1 cos θ − X 2 sin θ
x 2 = X 1 sin θ + X 2 cos θ.
(3.50)
(b) Equation (3.48) provides the components of F as
F 11 =
∂x 1
∂X 1
= cos θ,
F 12 =
∂x 1
∂X 2
= − sin θ
F 21 =
∂x 2
∂X 1
= sin θ,
F 22 =
∂x 2
∂X 2
= cos θ,
which are identical to the components of Q given above. For rigid-body
rotation, therefore, F is simply a rotation tensor, i.e., F = Q. In the absence
of both deformation and rotation, F = I.
Example 3.11 Suppose a body B deforms into body b 1 , which then deforms into b 2
(Fig. 3.8). The deformation gradient tensors from B to b 1 and b 1 to b 2 , respectively,
are F 1 and F 2 . Write the total deformation F in terms of F 1 and F 2 .
Solution
A differential line element dR in B deforms into the element dr 1 in b 1 ; then dr 1
deforms into dr 2 in b 2 . The total deformation gradient tensor F transforms dR into
dr 2 . Applying Eq. (3.42) to these mappings yields
dr 1 = F 1 · dR