

A Model for Electro-osmotic Flow of Pseudoplastic Nanofluids …
191
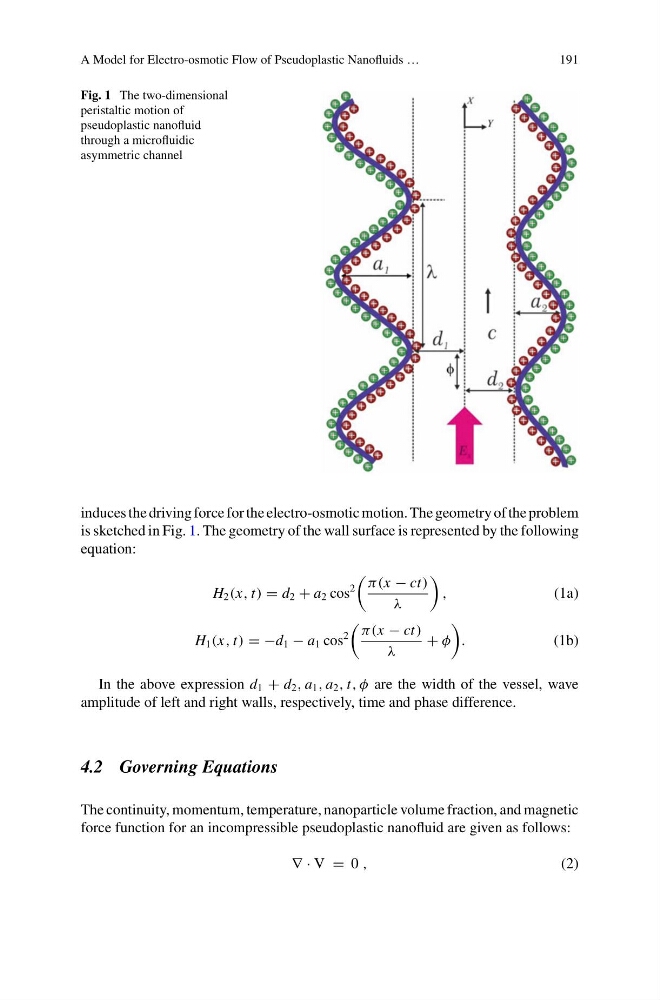
Fig. 1 The two-dimensional
peristaltic motion of
pseudoplastic nanofluid
through a microfluidic
asymmetric channel
induces the driving force for the electro-osmotic motion. The geometry of the problem
is sketched in Fig. 1. The geometry of the wall surface is represented by the following
equation:
H 2 (x, t) = d 2 + a 2 cos
2
π(x − ct)
λ
,
(1a)
H 1 (x, t) = −d 1 − a 1 cos
2
π(x − ct)
λ
+ φ
.
(1b)
In the above expression d 1 + d 2 , a 1 , a 2 , t, φ are the width of the vessel, wave
amplitude of left and right walls, respectively, time and phase difference.
4.2 Governing Equations
The continuity, momentum, temperature, nanoparticle volume fraction, and magnetic
force function for an incompressible pseudoplastic nanofluid are given as follows:
∇ · V = 0 ,
(2)