

M-SERVE and P-SERVE
61
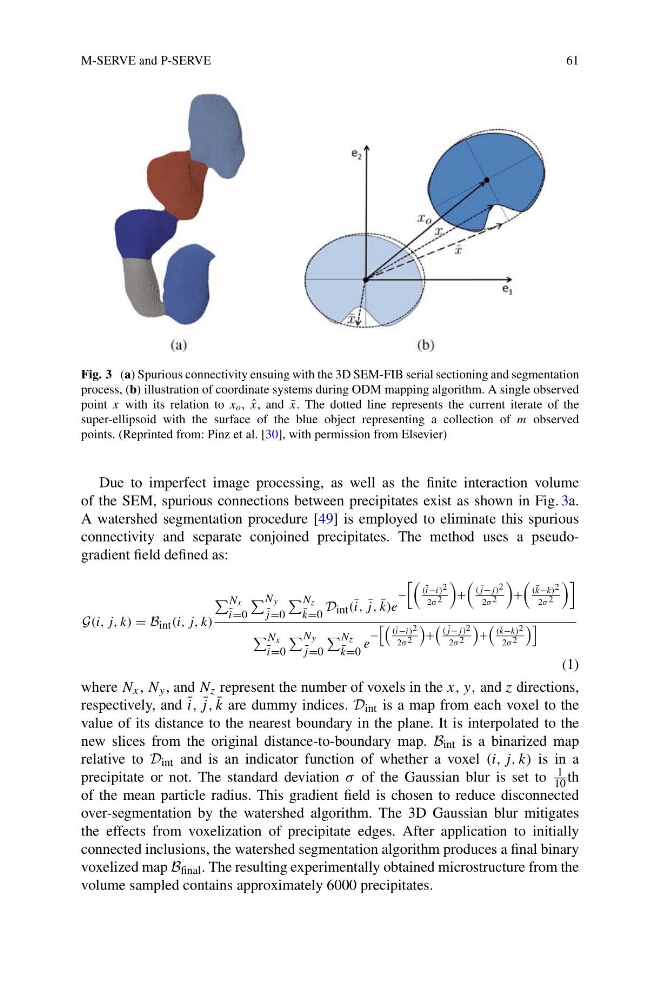
Fig. 3 (a) Spurious connectivity ensuing with the 3D SEM-FIB serial sectioning and segmentation
process, (b) illustration of coordinate systems during ODM mapping algorithm. A single observed
point x with its relation to x o , ˆ
x, and ¯
x. The dotted line represents the current iterate of the
super-ellipsoid with the surface of the blue object representing a collection of m observed
points. (Reprinted from: Pinz et al. [30], with permission from Elsevier)
Due to imperfect image processing, as well as the finite interaction volume
of the SEM, spurious connections between precipitates exist as shown in Fig. 3a.
A watershed segmentation procedure [49] is employed to eliminate this spurious
connectivity and separate conjoined precipitates. The method uses a pseudogradient field defined as:
G(i, j, k) = B int (i, j, k)
N x
¯
i=0
N y
¯
j =0
N z
¯
k=0
D int ( ¯
i, ¯
j, ¯
k)e
−
( ¯
i−i) 2
2σ 2
+
( ¯
j −j) 2
2σ 2
+
( ¯
k−k) 2
2σ 2
N x
¯
i=0
N y
¯
j =0
N z
¯
k=0
e
−
( ¯
i−i) 2
2σ 2
+
( ¯
j −j) 2
2σ 2
+
( ¯
k−k) 2
2σ 2
(1)
where N x , N y , and N z represent the number of voxels in the x, y, and z directions,
respectively, and ¯
i, ¯
j, ¯
k are dummy indices. D int is a map from each voxel to the
value of its distance to the nearest boundary in the plane. It is interpolated to the
new slices from the original distance-to-boundary map. B int is a binarized map
relative to D int and is an indicator function of whether a voxel (i, j, k) is in a
precipitate or not. The standard deviation σ of the Gaussian blur is set to
1
10 th
of the mean particle radius. This gradient field is chosen to reduce disconnected
over-segmentation by the watershed algorithm. The 3D Gaussian blur mitigates
the effects from voxelization of precipitate edges. After application to initially
connected inclusions, the watershed segmentation algorithm produces a final binary
voxelized map B final . The resulting experimentally obtained microstructure from the
volume sampled contains approximately 6000 precipitates.