

120 Seismology and Earth Structure
velocity structure for the composition of the earth. Later, in
Chapter 7, we discuss further how seismic data can be used to
study laterally variable velocity structure.
3.2 Refraction seismology
3.2.1 Flat layer method
The simplest approach to the inverse problem of determining
velocity at depth from travel times treats the earth as flat layers
of uniform-velocity material. We thus begin by deriving the
travel time curves for such a model, which show when seismic
waves arrive at a particular distance from a seismic source.
The travel times, especially those of waves that are critically
refracted at the interfaces, are used to find the velocities of the
layers and underlying halfspace and the layer thicknesses. As a
result, this technique is called refraction seismology.
Refraction seismology is used on vastly differing scales.
Near-surface structure at depths less than 100 meters can be
studied using a sledge hammer or a shotgun as a source and a
single receiver. Similar methods are used to study the crust and
the upper mantle, with earthquake or explosion sources and
many receivers at distances of hundreds of kilometers.
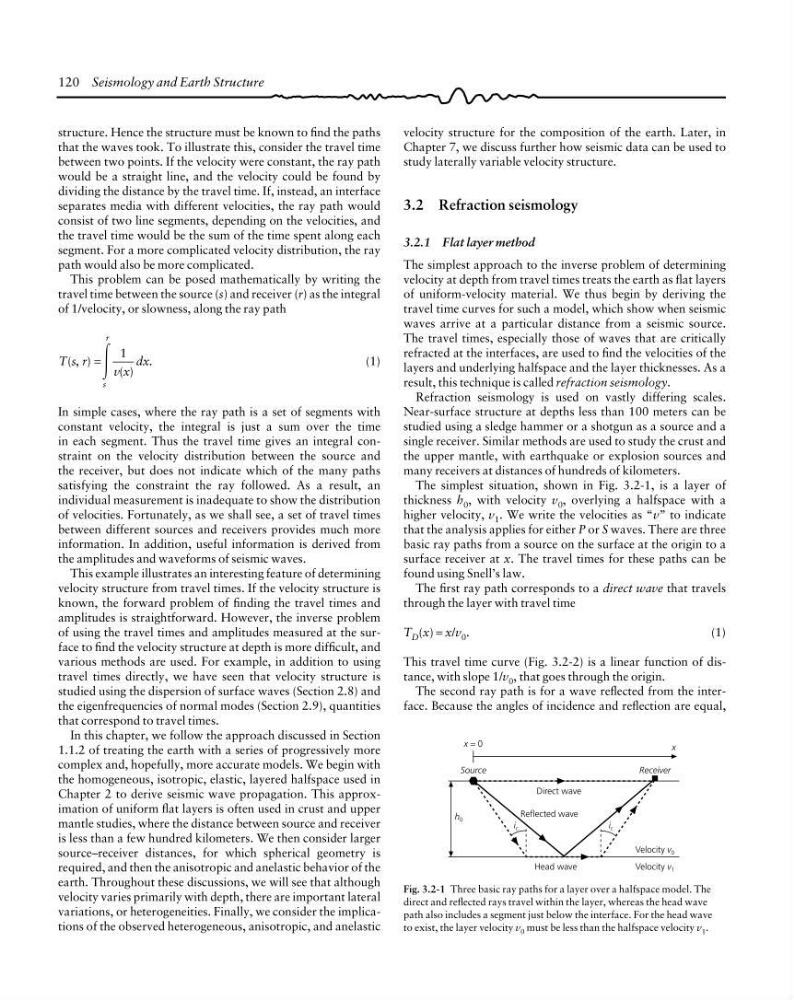
The simplest situation, shown in Fig. 3.2-1, is a layer of
thickness h 0 , with velocity v 0 , overlying a halfspace with a
higher velocity, v 1 . We write the velocities as “v” to indicate
that the analysis applies for either P or S waves. There are three
basic ray paths from a source on the surface at the origin to a
surface receiver at x. The travel times for these paths can be
found using Snell’s law.
The first ray path corresponds to a direct wave that travels
through the layer with travel time
T D (x) = x/v 0 .
(1)
This travel time curve (Fig. 3.2-2) is a linear function of distance, with slope 1/v 0 , that goes through the origin.
The second ray path is for a wave reflected from the interface. Because the angles of incidence and reflection are equal,
structure. Hence the structure must be known to find the paths
that the waves took. To illustrate this, consider the travel time
between two points. If the velocity were constant, the ray path
would be a straight line, and the velocity could be found by
dividing the distance by the travel time. If, instead, an interface
separates media with different velocities, the ray path would
consist of two line segments, depending on the velocities, and
the travel time would be the sum of the time spent along each
segment. For a more complicated velocity distribution, the ray
path would also be more complicated.
This problem can be posed mathematically by writing the
travel time between the source (s) and receiver (r) as the integral
of 1/velocity, or slowness, along the ray path
T s r
v x
dx
s
r
( , )
( )
.
=
Ύ
1
(1)
In simple cases, where the ray path is a set of segments with
constant velocity, the integral is just a sum over the time
in each segment. Thus the travel time gives an integral constraint on the velocity distribution between the source and
the receiver, but does not indicate which of the many paths
satisfying the constraint the ray followed. As a result, an
individual measurement is inadequate to show the distribution
of velocities. Fortunately, as we shall see, a set of travel times
between different sources and receivers provides much more
information. In addition, useful information is derived from
the amplitudes and waveforms of seismic waves.
This example illustrates an interesting feature of determining
velocity structure from travel times. If the velocity structure is
known, the forward problem of finding the travel times and
amplitudes is straightforward. However, the inverse problem
of using the travel times and amplitudes measured at the surface to find the velocity structure at depth is more difficult, and
various methods are used. For example, in addition to using
travel times directly, we have seen that velocity structure is
studied using the dispersion of surface waves (Section 2.8) and
the eigenfrequencies of normal modes (Section 2.9), quantities
that correspond to travel times.
In this chapter, we follow the approach discussed in Section
1.1.2 of treating the earth with a series of progressively more
complex and, hopefully, more accurate models. We begin with
the homogeneous, isotropic, elastic, layered halfspace used in
Chapter 2 to derive seismic wave propagation. This approximation of uniform flat layers is often used in crust and upper
mantle studies, where the distance between source and receiver
is less than a few hundred kilometers. We then consider larger
source–receiver distances, for which spherical geometry is
required, and then the anisotropic and anelastic behavior of the
earth. Throughout these discussions, we will see that although
velocity varies primarily with depth, there are important lateral
variations, or heterogeneities. Finally, we consider the implications of the observed heterogeneous, anisotropic, and anelastic
Fig. 3.2-1 Three basic ray paths for a layer over a halfspace model. The
direct and reflected rays travel within the layer, whereas the head wave
path also includes a segment just below the interface. For the head wave
to exist, the layer velocity v 0 must be less than the halfspace velocity v 1 .
x = 0
Source
x
Receiver
Direct wave
Reflected wave
i c
i c
h 0
Head wave
Velocity v 1
Velocity v 0