

430
G. Osada et al.
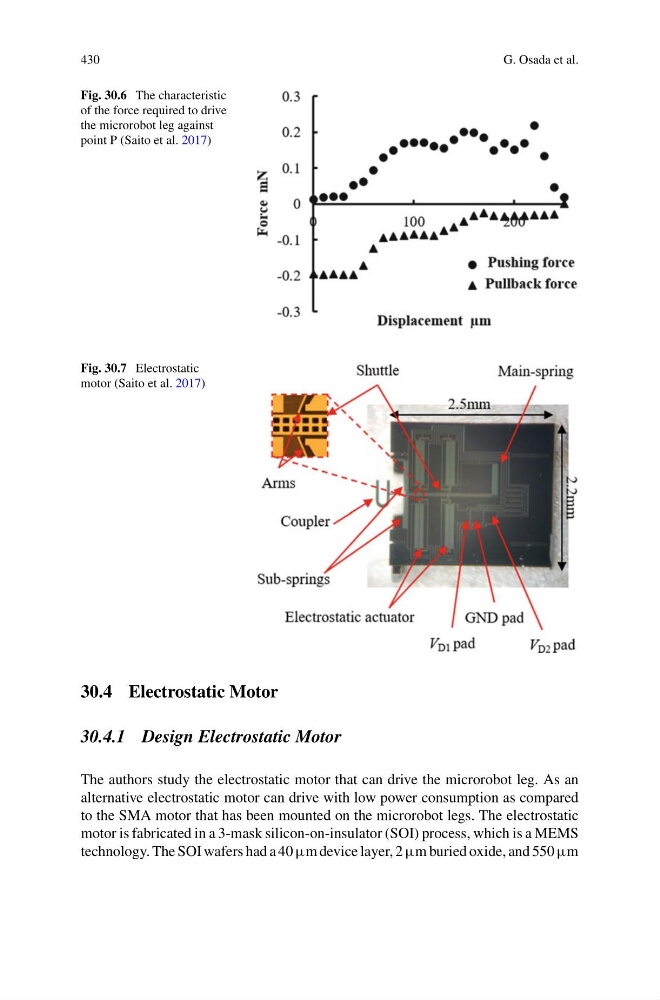
Fig. 30.6 The characteristic
of the force required to drive
the microrobot leg against
point P (Saito et al. 2017)
Fig. 30.7 Electrostatic
motor (Saito et al. 2017)
30.4 Electrostatic Motor
30.4.1 Design Electrostatic Motor
The authors study the electrostatic motor that can drive the microrobot leg. As an
alternative electrostatic motor can drive with low power consumption as compared
to the SMA motor that has been mounted on the microrobot legs. The electrostatic
motor is fabricated in a 3-mask silicon-on-insulator (SOI) process, which is a MEMS
technology. The SOI wafers had a 40 µm device layer, 2 µm buried oxide, and 550 µm