

The Linearization of the Equations of Motion
69
where the relation (4.1) is used, and
b
= 1
E x0
χ e0
(h + n e ) +
B y0
χ m0
n b
y.
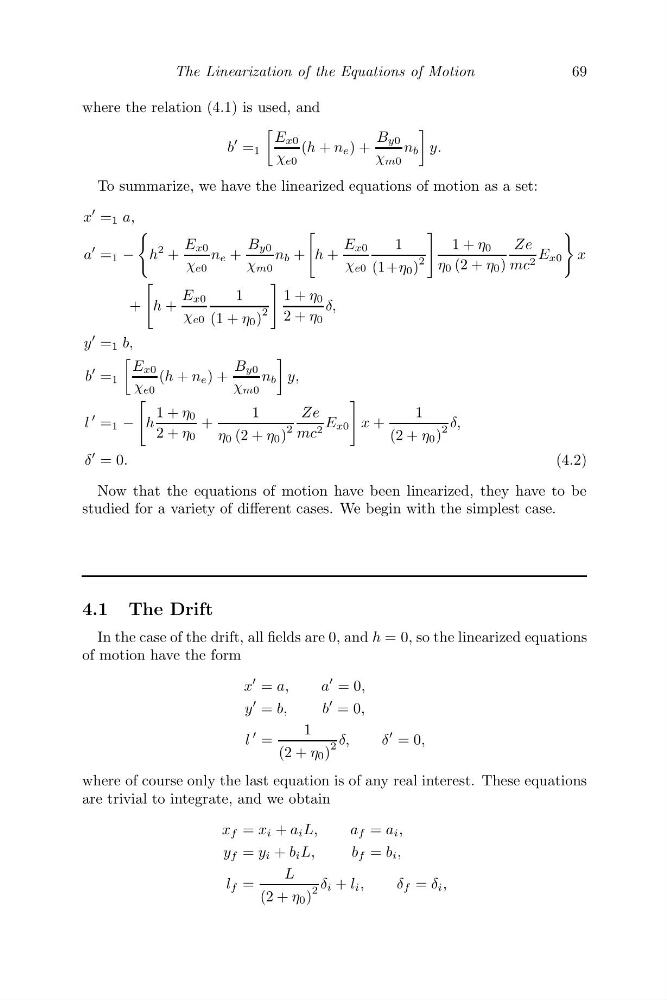
To summarize, we have the linearized equations of motion as a set:
x
= 1 a,
a
= 1 −
h
2 +
E x0
χ e0
n e +
B y0
χ m0
n b +
h +
E x0
χ e0
1
(1+η 0 )
2
1 + η 0
η 0 (2 + η 0 )
Ze
mc 2 E x0
x
+
h +
E x0
χ e0
1
(1 + η 0 )
2
1 + η 0
2 + η 0
δ,
y
= 1 b,
b
= 1
E x0
χ e0
(h + n e ) +
B y0
χ m0
n b
y,
l
= 1 −
h
1 + η 0
2 + η 0
+
1
η 0 (2 + η 0 )
2
Ze
mc 2 E x0
x +
1
(2 + η 0 )
2 δ,
δ
= 0.
(4.2)
Now that the equations of motion have been linearized, they have to be
studied for a variety of different cases. We begin with the simplest case.
4.1 The Drift
In the case of the drift, all fields are 0, and h = 0, so the linearized equations
of motion have the form
x
= a,
a
= 0,
y
= b,
b
= 0,
l
=
1
(2 + η 0 )
2 δ,
δ
= 0,
where of course only the last equation is of any real interest. These equations
are trivial to integrate, and we obtain
x f = x i + a i L,
a f = a i ,
y f = y i + b i L,
b f = b i ,
l f =
L
(2 + η 0 )
2 δ i + l i ,
δ f = δ i ,