

The Linearization of the Equations of Motion
103
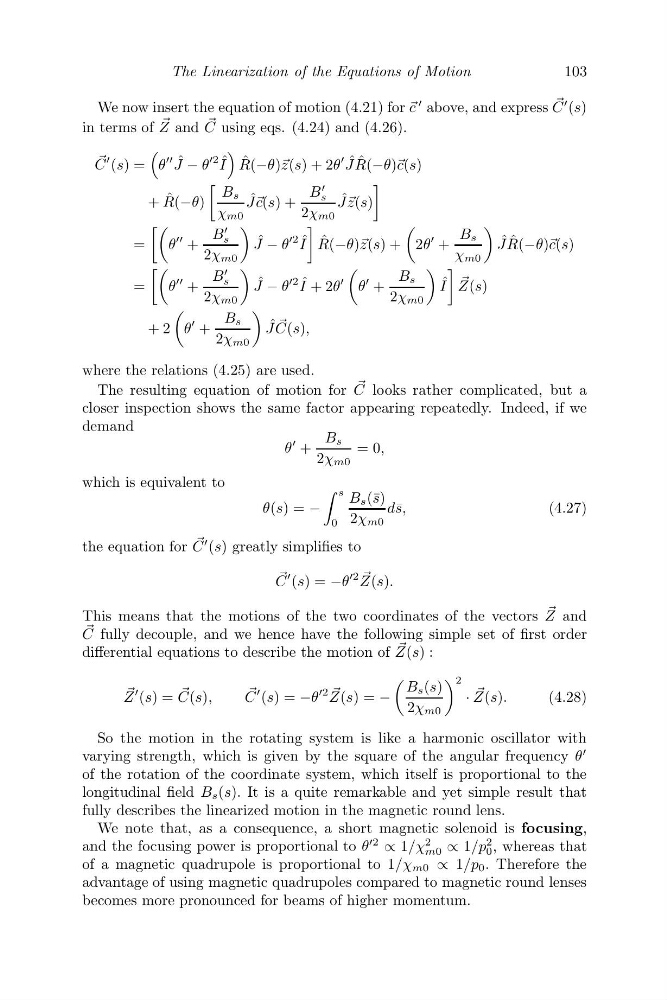
We now insert the equation of motion (4.21) for c
above, and express
C
(s)
in terms of
Z and
C using eqs. (4.24) and (4.26).
C
(s) =
θ
ˆ
J − θ
2 ˆ
I
ˆ
R(−θ) z(s) + 2θ
ˆ
J ˆ
R(−θ) c(s)
+ ˆ
R(−θ)
B s
χ m0
ˆ
JJ c(s) +
B
s
2χ m0
ˆ
JJ z(s)
=
θ
+
B
s
2χ m0
ˆ
J − θ
2 ˆ
I
ˆ
R(−θ) z(s) +
2θ
+
B s
χ m0
ˆ
J ˆ
R(−θ) c(s)
=
θ
+
B
s
2χ m0
ˆ
J − θ
2 ˆ
I + 2θ
θ
+
B s
2χ m0
ˆ
I
Z(s)
+ 2
θ
+
B s
2χ m0
ˆ
J
C(s),
where the relations (4.25) are used.
The resulting equation of motion for
C looks rather complicated, but a
closer inspection shows the same factor appearing repeatedly. Indeed, if we
demand
θ
+
B s
2χ m0
= 0,
which is equivalent to
θ(s) = −
s
0
B s (¯ s)
2χ m0
d¯ s,
(4.27)
the equation for
C
(s) greatly simplifies to
C
(s) = −θ
2
Z(s).
This means that the motions of the two coordinates of the vectors
Z and
C fully decouple, and we hence have the following simple set of first order
differential equations to describe the motion of
Z(s) :
Z
(s) =
C(s),
C
(s) = −θ
2
Z(s) = −
B s (s)
2χ m0
2
·
Z(s).
(4.28)
So the motion in the rotating system is like a harmonic oscillator with
varying strength, which is given by the square of the angular frequency θ
of the rotation of the coordinate system, which itself is proportional to the
longitudinal field B s (s). It is a quite remarkable and yet simple result that
fully describes the linearized motion in the magnetic round lens.
We note that, as a consequence, a short magnetic solenoid is focusing,
and the focusing power is proportional to θ
2
∝ 1/χ
2
m0 ∝ 1/p
2
0 , whereas that
of a magnetic quadrupole is proportional to 1/χ m0 ∝ 1/p 0 . Therefore the
advantage of using magnetic quadrupoles compared to magnetic round lenses
becomes more pronounced for beams of higher momentum.