

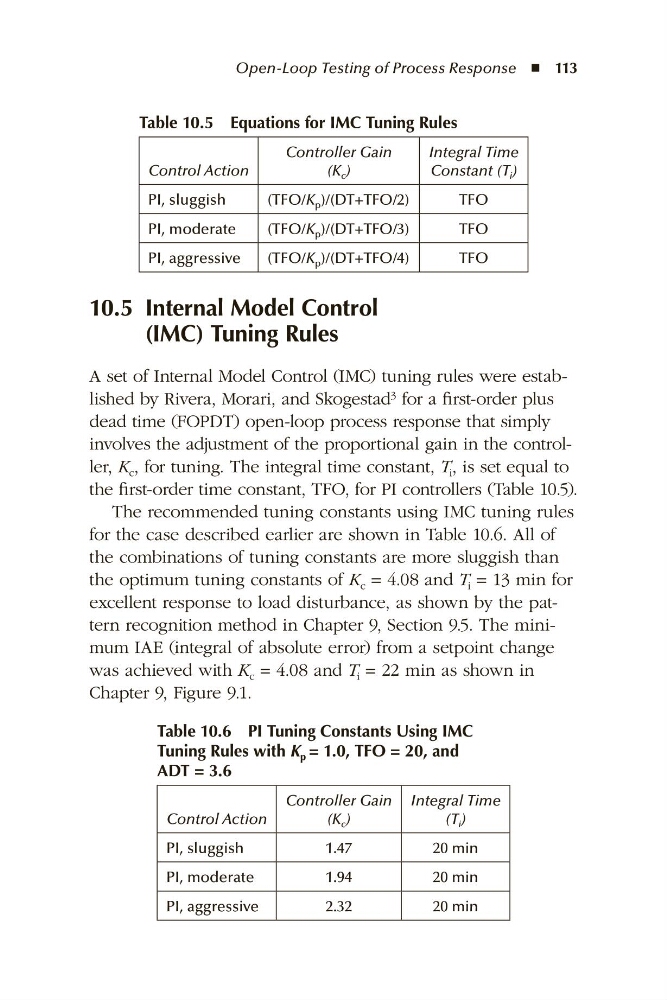
Table 10.5 Equations for IMC Tuning Rules
Control Action
Controller Gain
(K c )
Integral Time
Constant (T i )
PI, sluggish
(TFO/K p )/(DT+TFO/2)
TFO
PI, moderate
(TFO/K p )/(DT+TFO/3)
TFO
PI, aggressive
(TFO/K p )/(DT+TFO/4)
TFO
Open-Loop Testing of Process Response ◾ 113
10.5 Internal Model Control
(IMC) Tuning Rules
A set of Internal Model Control (IMC) tuning rules were established by Rivera, Morari, and Skogestad 3 for a first-order plus
dead time (FOPDT) open-loop process response that simply
involves the adjustment of the proportional gain in the controller, K c , for tuning. The integral time constant, T i , is set equal to
the first-order time constant, TFO, for PI controllers (Table 10.5).
The recommended tuning constants using IMC tuning rules
for the case described earlier are shown in Table 10.6. All of
the combinations of tuning constants are more sluggish than
the optimum tuning constants of K c = 4.08 and T i = 13 min for
excellent response to load disturbance, as shown by the pattern recognition method in Chapter 9, Section 9.5. The minimum IAE (integral of absolute error) from a setpoint change
was achieved with K c = 4.08 and T i = 22 min as shown in
Chapter 9, Figure 9.1.
Table 10.6 PI Tuning Constants Using IMC
Tuning Rules with K p = 1.0, TFO = 20, and
ADT = 3.6
Control Action
Controller Gain
(K c )
Integral Time
(T i )
PI, sluggish
1.47
20 min
PI, moderate
1.94
20 min
PI, aggressive
2.32
20 min