

Chapter VII
Wave flume
89
Bottom boundary condition for horizontal bottom
í µí¼í µí¼ 1
í µí¼í µí±§
= 0, í µí±í µí±¡ í µí±§ = −ℎ
Equation VII-12
Kinematic and dynamic free surface boundary condition
í µí¼
2 í µí¼ 1
í µí¼í µí±¡ 2 + í µí±
í µí¼í µí¼ 1
í µí¼í µí±§
= 0, í µí±í µí±¡ í µí±§ = 0
Equation VII-13
General wave board boundary condition
í µí¼í µí¼ 1
í µí¼í µí±¥
= (1 +
í µí±§
ℎ
)
í µí±í µí± 1
í µí±í µíí µí±í µí±¡ í µí±¥ = 0
Equation VII-14
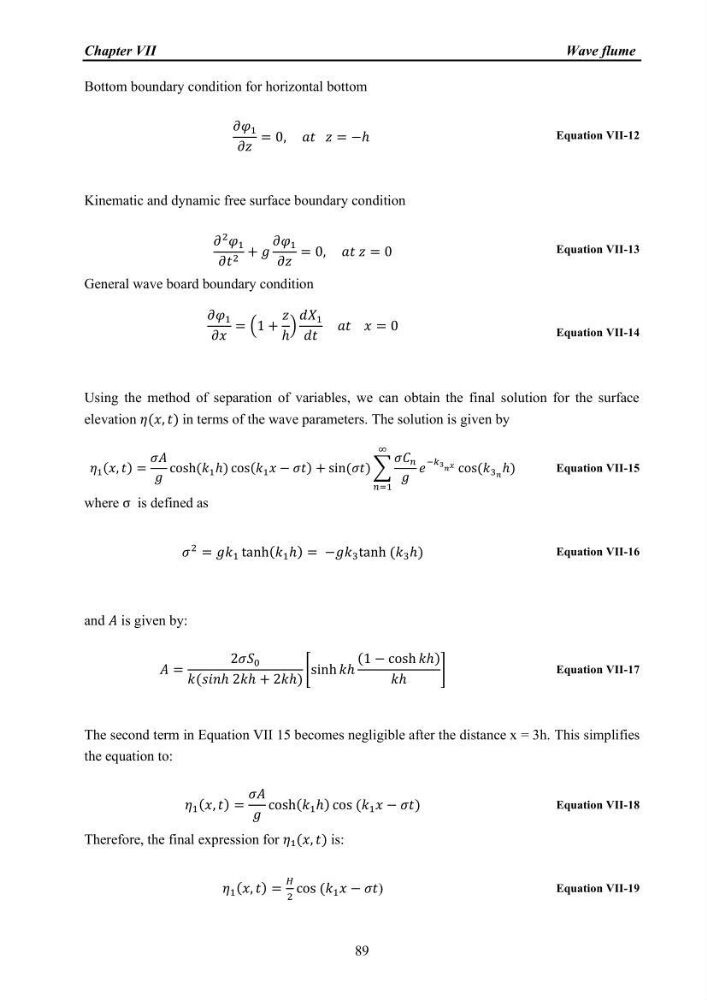
Using the method of separation of variables, we can obtain the final solution for the surface
elevation í µí¼(í µí±¥, í µí±¡) in terms of the wave parameters. The solution is given by
í µí¼ 1 (í µí±¥, í µí±¡) =
í µí¼í µí°´
í µí±
cosh(í µí± 1 ℎ) cos(í µí± 1 í µí±¥ − í µí¼í µí±¡) + sin(í µí¼í µí±¡) ∑
í µí¼í µí°¶ í µí±
í µí±
í µí±
−í µí± 3 í µí± í µí±¥
∞
í µí±=1
cos(í µí± 3 í µí± ℎ)
Equation VII-15
where σ is defined as
í µí¼
2 = í µí±í µí± 1 tanh(í µí± 1 ℎ) = −í µí±í µí± 3 tanh (í µí± 3 ℎ)
Equation VII-16
and í µí°´ is given by:
í µí°´ =
2í µí¼í µí± 0
í µí±(í µí± í µí±í µí±ℎ 2í µí±ℎ + 2í µí±ℎ)
[sinh í µí±ℎ
(1 − cosh í µí±ℎ)
í µí±ℎ
]
Equation VII-17
The second term in Equation VII 15 becomes negligible after the distance x = 3h. This simplifies
the equation to:
í µí¼ 1 (í µí±¥, í µí±¡) =
í µí¼í µí°´
í µí±
cosh(í µí± 1 ℎ) cos (í µí± 1 í µí±¥ − í µí¼í µí±¡)
Equation VII-18
Therefore, the final expression for í µí¼₁(í µí±¥, í µí±¡) is:
í µí¼ 1 (í µí±¥, í µí±¡) =
í µí°»
2
cos (í µí± 1 í µí±¥ − í µí¼í µí±¡)
Equation VII-19