

Chapter VII
Wave flume
87
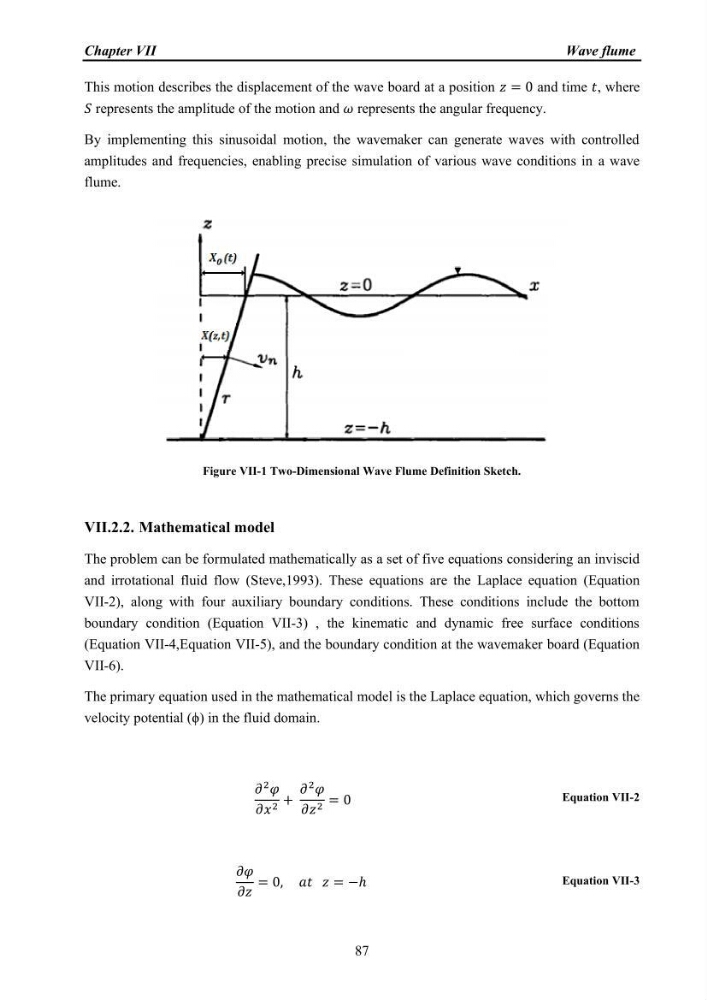
This motion describes the displacement of the wave board at a position í µí±§ = 0 and time í µí±¡, where
í µí± represents the amplitude of the motion and í µí¼ represents the angular frequency.
By implementing this sinusoidal motion, the wavemaker can generate waves with controlled
amplitudes and frequencies, enabling precise simulation of various wave conditions in a wave
flume.
Figure VII-1 Two-Dimensional Wave Flume Definition Sketch.
VII.2.2. Mathematical model
The problem can be formulated mathematically as a set of five equations considering an inviscid
and irrotational fluid flow (Steve,1993). These equations are the Laplace equation (Equation
VII-2), along with four auxiliary boundary conditions. These conditions include the bottom
boundary condition (Equation VII-3) , the kinematic and dynamic free surface conditions
(Equation VII-4,Equation VII-5), and the boundary condition at the wavemaker board (Equation
VII-6).
The primary equation used in the mathematical model is the Laplace equation, which governs the
velocity potential (ϕ) in the fluid domain.
í µí¼
2 í µí¼
í µí¼í µí±¥ 2 +
í µí¼
2 í µí¼
í µí¼í µí±§ 2 = 0
Equation VII-2
í µí¼í µí¼
í µí¼í µí±§
= 0, í µí±í µí±¡ í µí±§ = −ℎ
Equation VII-3