

6.5 Compression of Barrel-Shaped Bodies
63
c p =
1
π(1 − e 2 )
3
3
2
(1 − e 2 ) 2
E 2 (e)
,
c a =
3
3
2
E(e)
1 − e 2 , c δ = K(e)
3
9
4
(1 − e 2 )
E(e)
.
6.5 Compression of Barrel-Shaped Bodies
6.5.1 Rotation Bodies with Parallel Axes
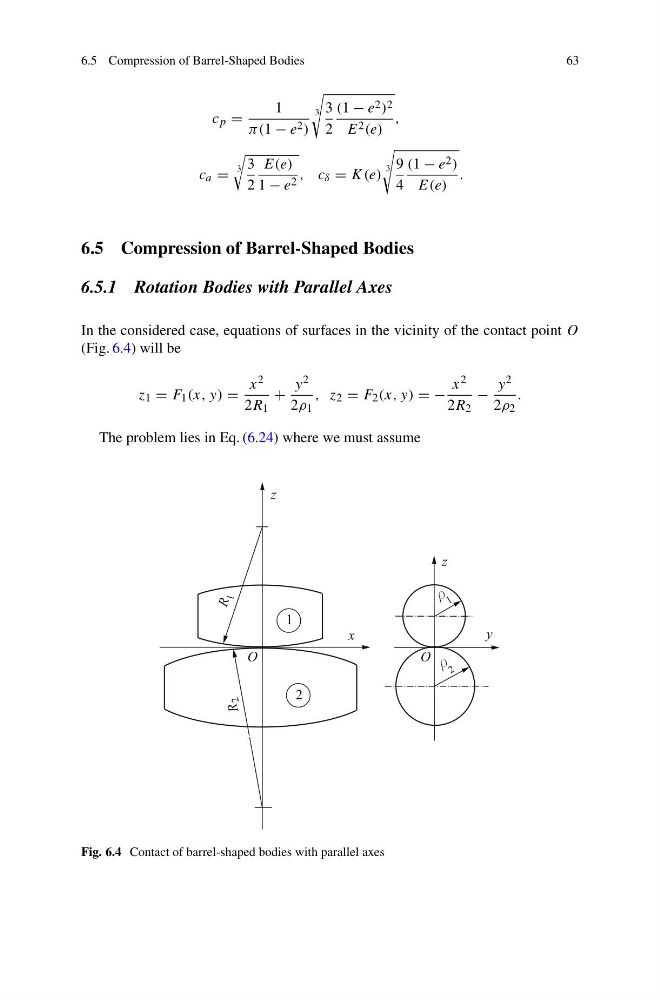
In the considered case, equations of surfaces in the vicinity of the contact point O
(Fig. 6.4) will be
z 1 = F 1 (x, y) =
x 2
2R 1
+
y 2
2ρ 1
, z 2 = F 2 (x, y) = −
x 2
2R 2
−
y 2
2ρ 2
.
The problem lies in Eq. (6.24) where we must assume
Fig. 6.4 Contact of barrel-shaped bodies with parallel axes