

32.7 More About Incompatible Deformations
427
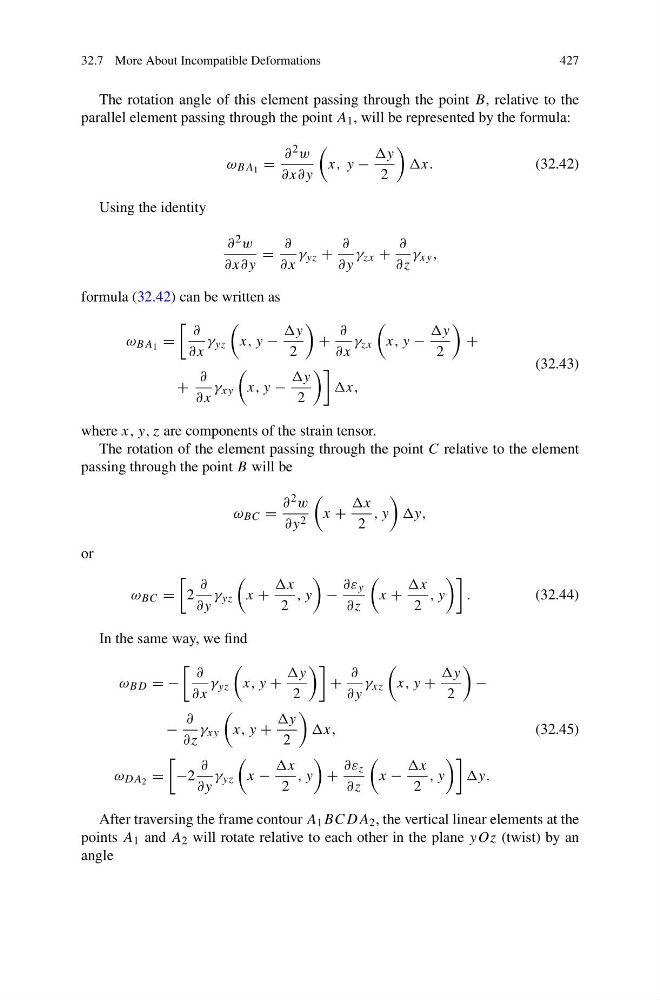
The rotation angle of this element passing through the point B, relative to the
parallel element passing through the point A 1 , will be represented by the formula:
ω BA 1 =
∂ 2 w
∂x∂y
x, y −
y
2
x.
(32.42)
Using the identity
∂ 2 w
∂x∂y
=
∂
∂x
γ yz +
∂
∂y
γ zx +
∂
∂z
γ xy ,
formula (32.42) can be written as
ω BA 1 =
∂
∂x
γ yz
x, y −
y
2
+
∂
∂x
γ zx
x, y −
y
2
+
+
∂
∂x
γ xy
x, y −
y
2
x,
(32.43)
where x, y, z are components of the strain tensor.
The rotation of the element passing through the point C relative to the element
passing through the point B will be
ω BC =
∂ 2 w
∂y 2
x +
x
2
, y
y,
or
ω BC =
2
∂
∂y
γ yz
x +
x
2
, y
−
∂ε y
∂z
x +
x
2
, y
.
(32.44)
In the same way, we find
ω BD = −
∂
∂x
γ yz
x, y +
y
2
+
∂
∂y
γ xz
x, y +
y
2
−
−
∂
∂z
γ xy
x, y +
y
2
x,
ω DA 2 =
−2
∂
∂y
γ yz
x −
x
2
, y
+
∂ε z
∂z
x −
x
2
, y
y.
(32.45)
After traversing the frame contour A 1 BCDA 2 , the vertical linear elements at the
points A 1 and A 2 will rotate relative to each other in the plane yOz (twist) by an
angle