

354
27 Non-elastic Uniaxial Elongation–Compression
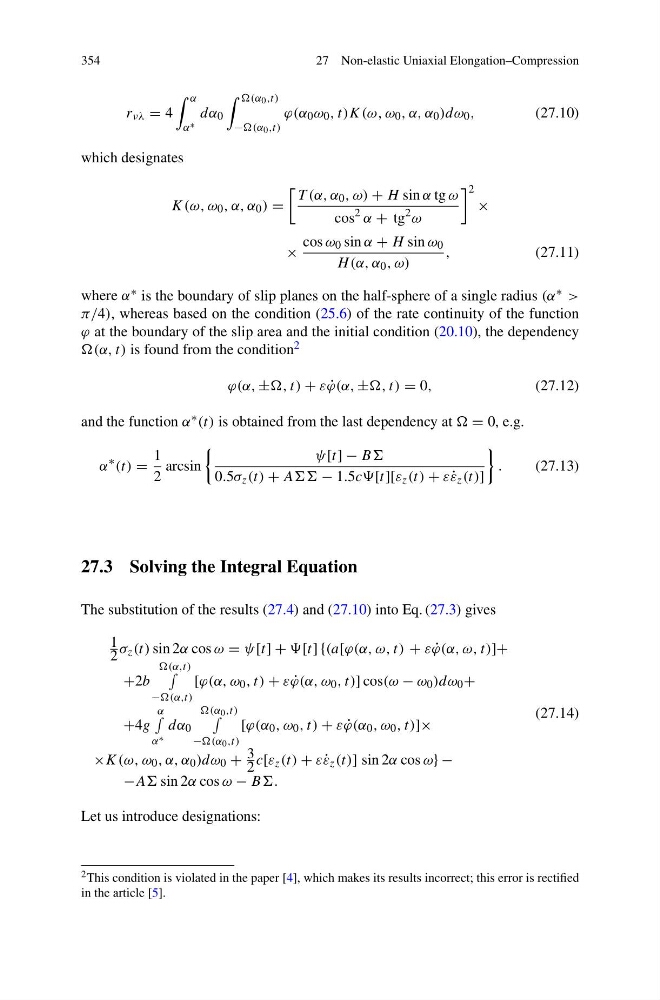
r νλ = 4
α
α ∗
dα 0
(α 0 ,t)
−(α 0 ,t)
ϕ(α 0 ω 0 , t)K(ω, ω 0 , α, α 0 )dω 0 ,
(27.10)
which designates
K(ω, ω 0 , α, α 0 ) =
T (α, α 0 , ω) + H sin α tg ω
cos
2 α + tg
2 ω
2
×
×
cos ω 0 sin α + H sin ω 0
H (α, α 0 , ω)
,
(27.11)
where α ∗ is the boundary of slip planes on the half-sphere of a single radius (α ∗ >
π/4), whereas based on the condition (25.6) of the rate continuity of the function
ϕ at the boundary of the slip area and the initial condition (20.10), the dependency
t) is found from the condition 2
ϕ(α, ± t) + ε ˙
ϕ(α, ±, t) = 0,
(27.12)
and the function α ∗ (t) is obtained from the last dependency at = 0, e.g.
α
∗ (t) =
1
2
arcsin
ψ[t] − BB
0.5σ z (t) + AAA − 1.5cc[t][ε z (t) + ε ˙
ε z (t)]
.
(27.13)
27.3 Solving the Integral Equation
The substitution of the results (27.4) and (27.10) into Eq. (27.3) gives
1
2 σ z (t) sin 2α cos ω = ψ[t] + [t] {(a[ϕ(α, ω, t) + ε ˙
ϕ(α, ω, t)]+
+2b
(α,t)
−(α,t)
[ϕ(α, ω 0 , t) + ε ˙
ϕ(α, ω 0 , t)] cos(ω − ω 0 )dω 0 +
+4g
α
α ∗
dα 0
(α 0 ,t)
−(α 0 ,t)
[ϕ(α 0 , ω 0 , t) + ε ˙
ϕ(α 0 , ω 0 , t)]×
×K(ω, ω 0 , α, α 0 )dω 0 + 3
2 c[ε z (t) + ε ˙
ε z (t)] sin 2α cos ω} −
−AA sin 2α cos ω − BB.
(27.14)
Let us introduce designations:
2 This condition is violated in the paper [4], which makes its results incorrect; this error is rectified
in the article [5].