

20.4 Definition of Principal Strains
309
The value r νλ defined by formulas (20.21)–(20.22) is called the tensor slip rate.
By substituting formulas (20.17) into the expression (20.21), we can obtain
r νλ =
{W }
{L}
ϕ(α 0 , β 0 , ω 0 )(η λ cos ω 0 + ξ λ sin ω 0 ) cos
2 w 0 dω 0 dw 0 .
(20.23)
Let us set the directions of the axes ν and λ using the angles α, β, and ω counted
under the same rules as the angles α 0 , β 0 , and ω 0 for the vectors #» n and
#»
l . Then the
condition (20.22) can be represented as
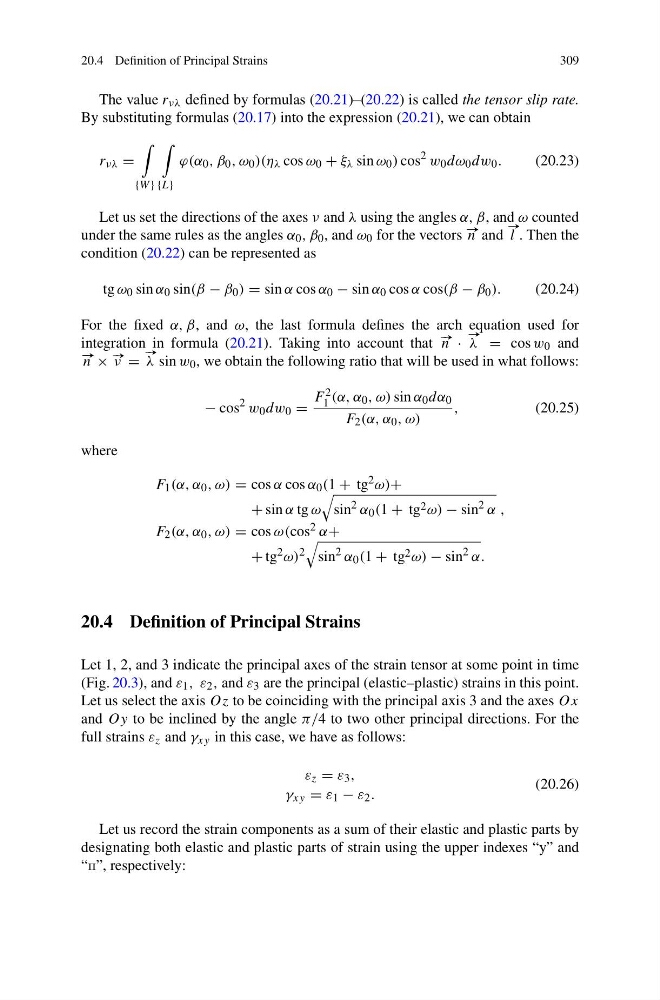
tg ω 0 sin α 0 sin(β − β 0 ) = sin α cos α 0 − sin α 0 cos α cos(β − β 0 ).
(20.24)
For the fixed α, β, and ω, the last formula defines the arch equation used for
integration in formula (20.21). Taking into account that #» n ·
#»
λ = cos w 0 and
#» n × #» ν =
#»
λ sin w 0 , we obtain the following ratio that will be used in what follows:
− cos
2 w 0 dw 0 =
F 2
1 (α, α 0 , ω) sin α 0 dα 0
F 2 (α, α 0 , ω)
,
(20.25)
where
F 1 (α, α 0 , ω) = cos α cos α 0 (1 + tg 2 ω)+
+ sin α tg ω
sin
2 α 0 (1 + tg 2 ω) − sin
2 α ,
F 2 (α, α 0 , ω) = cos ω(cos 2 α+
+ tg 2 ω) 2
sin
2 α 0 (1 + tg 2 ω) − sin
2 α.
20.4 Definition of Principal Strains
Let 1, 2, and 3 indicate the principal axes of the strain tensor at some point in time
(Fig. 20.3), and ε 1 , ε 2 , and ε 3 are the principal (elastic–plastic) strains in this point.
Let us select the axis Oz to be coinciding with the principal axis 3 and the axes Ox
and Oy to be inclined by the angle π/4 to two other principal directions. For the
full strains ε z and γ xy in this case, we have as follows:
ε z = ε 3 ,
γ xy = ε 1 − ε 2 .
(20.26)
Let us record the strain components as a sum of their elastic and plastic parts by
designating both elastic and plastic parts of strain using the upper indexes “y” and
“p”, respectively: