

176
13 Initial Concepts of Plasticity Theory
σ
1 =
2
3
σ ? cos ,
σ
2 =
2
3
σ ? cos
−
2π
3
,
σ
3 =
2
3
σ ? cos
−
4π
3
.
(13.40)
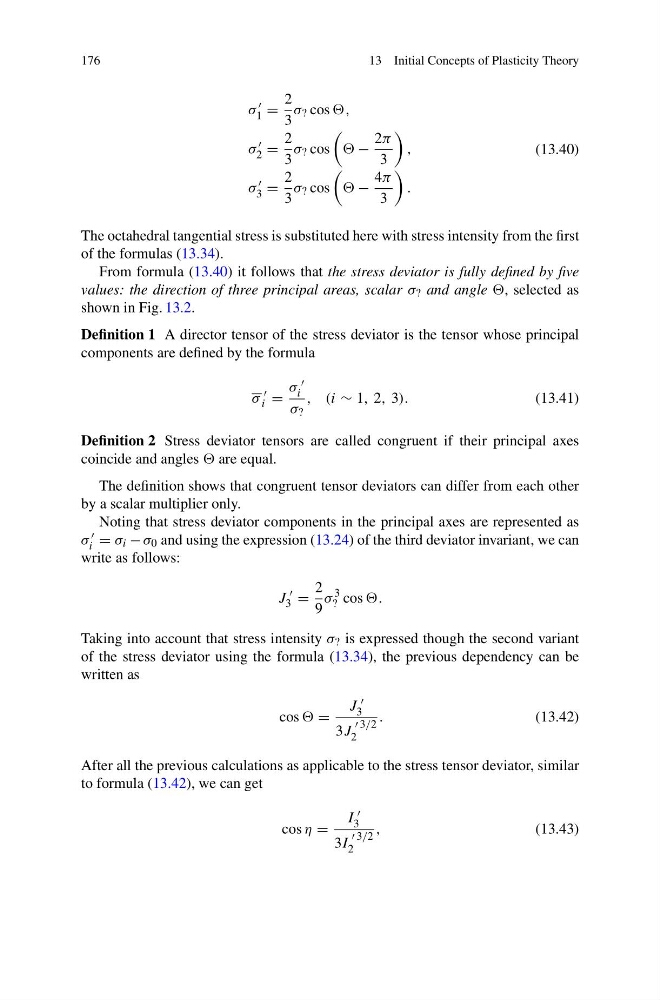
The octahedral tangential stress is substituted here with stress intensity from the first
of the formulas (13.34).
From formula (13.40) it follows that the stress deviator is fully defined by five
values: the direction of three principal areas, scalar σ ? and angle , selected as
shown in Fig. 13.2.
Definition 1 A director tensor of the stress deviator is the tensor whose principal
components are defined by the formula
σ
i =
σ
i
σ ?
, (i ∼ 1, 2, 3).
(13.41)
Definition 2 Stress deviator tensors are called congruent if their principal axes
coincide and angles are equal.
The definition shows that congruent tensor deviators can differ from each other
by a scalar multiplier only.
Noting that stress deviator components in the principal axes are represented as
σ
i = σ i − σ 0 and using the expression (13.24) of the third deviator invariant, we can
write as follows:
J
3 =
2
9
σ
3
? cos .
Taking into account that stress intensity σ ? is expressed though the second variant
of the stress deviator using the formula (13.34), the previous dependency can be
written as
cos =
J
3
3J
3/2
2
.
(13.42)
After all the previous calculations as applicable to the stress tensor deviator, similar
to formula (13.42), we can get
cos η =
I
3
3I
3/2
2
,
(13.43)