

24 3D Object Classification, Visual Search …
373
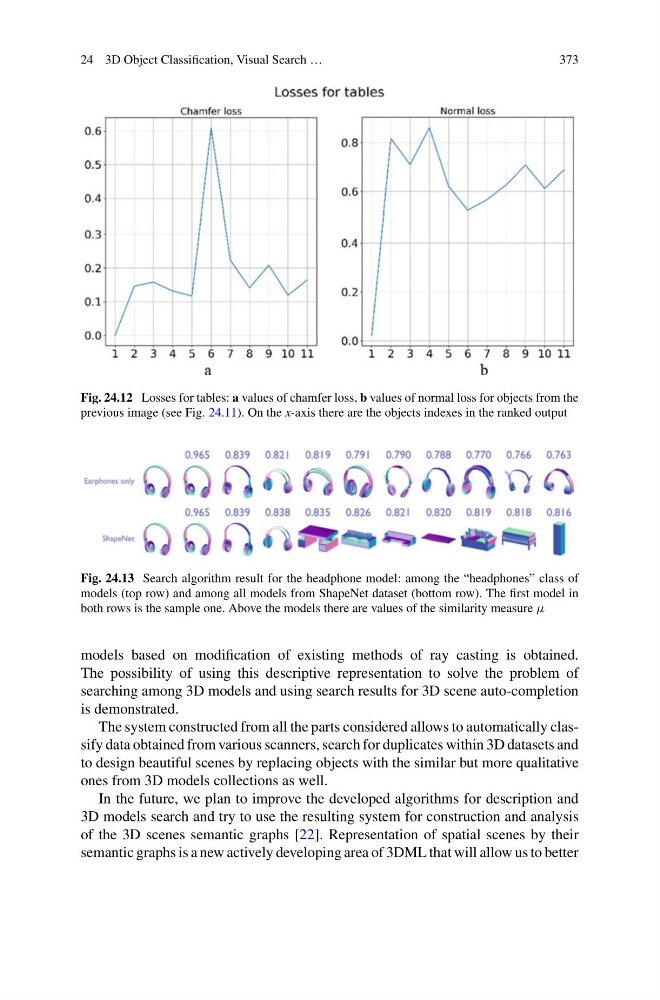
Fig. 24.12 Losses for tables: a values of chamfer loss, b values of normal loss for objects from the
previous image (see Fig. 24.11). On the x-axis there are the objects indexes in the ranked output
Fig. 24.13 Search algorithm result for the headphone model: among the “headphones” class of
models (top row) and among all models from ShapeNet dataset (bottom row). The first model in
both rows is the sample one. Above the models there are values of the similarity measure μ
models based on modification of existing methods of ray casting is obtained.
The possibility of using this descriptive representation to solve the problem of
searching among 3D models and using search results for 3D scene auto-completion
is demonstrated.
The system constructed from all the parts considered allows to automatically classify data obtained from various scanners, search for duplicates within 3D datasets and
to design beautiful scenes by replacing objects with the similar but more qualitative
ones from 3D models collections as well.
In the future, we plan to improve the developed algorithms for description and
3D models search and try to use the resulting system for construction and analysis
of the 3D scenes semantic graphs [22]. Representation of spatial scenes by their
semantic graphs is a new actively developing area of 3DML that will allow us to better