

358
V. L. Kondarattsev et al.
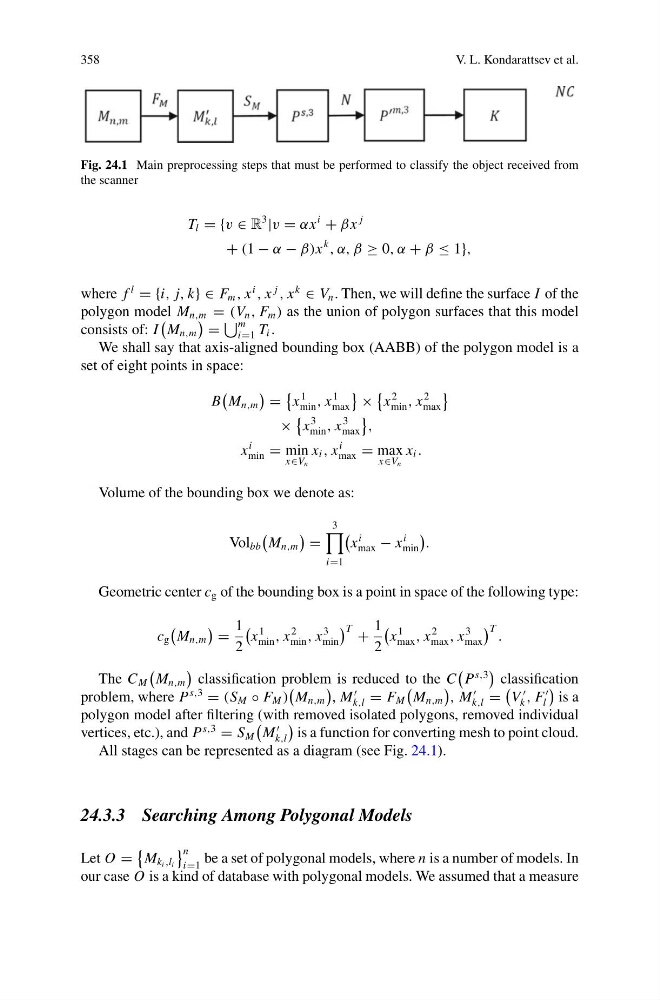
Fig. 24.1 Main preprocessing steps that must be performed to classify the object received from
the scanner
T l = {v ∈ R
3
|v = αx
i
+ βx
j
+ (1 − α − β)x
k
, α, β ≥ 0, α + β ≤ 1},
where f
l
= {i, j, k} ∈ F m , x
i
, x
j
, x
k
∈ V n . Then, we will define the surface I of the
polygon model M n,m = (V n , F m ) as the union of polygon surfaces that this model
consists of: I
M n,m
=
m
i=1 T i .
We shall say that axis-aligned bounding box (AABB) of the polygon model is a
set of eight points in space:
B
M n,m
=
x
1
min , x
1
max
×
x
2
min , x
2
max
×
x
3
min , x
3
max
,
x
i
min = min
x∈V n
x i , x
i
max = max
x∈V n
x i .
Volume of the bounding box we denote as:
Vol bb
M n,m
=
3
i=1
x
i
max − x
i
min
.
Geometric center c g of the bounding box is a point in space of the following type:
c g
M n,m
=
1
2
x
1
min , x
2
min , x
3
min
T +
1
2
x
1
max , x
2
max , x
3
max
T .
The C M
M n,m
classification problem is reduced to the C
P
s,3
classification
problem, where P
s,3
= (S M ◦ F M )
M n,m
, M
k,l = F M
M n,m
, M
k,l =
V
k , F
l
is a
polygon model after filtering (with removed isolated polygons, removed individual
vertices, etc.), and P
s,3
= S M
M
k,l
is a function for converting mesh to point cloud.
All stages can be represented as a diagram (see Fig. 24.1).
24.3.3 Searching Among Polygonal Models
Let O =
M k i ,l i
n
i=1
be a set of polygonal models, where n is a number of models. In
our case O is a kind of database with polygonal models. We assumed that a measure