

16 Application of Multi-agent Optimization Methods …
227
Number b 2 helps to reduce the population individuals (worst). The worst b 2 individuals are removed from the population, and new b 2 individuals are added to maintain the same number of individuals NP. Recommended value for this parameter is
b 2 ∈ [4, 8].
16.2.3 Multi-agent Optimization Algorithm Using Linear
Regulators for Agents Motion Control
Solution search strategy. It is required to generate a population of N P agents on
a set of admissible solutions D using a uniform distribution law. The search for an
extremum is realized in a given number of passes P max . In the next pass, all agents
move under the action of appropriate control for a certain number of iterations.
Let suppose the equation of the agent motion of the form of Eq. 16.18, where x is
n-dimensional vector of agent position, v is n-dimensional vector of agent velocity,
t is the time, t 0 is the initial time in the next passage, x 0 is the initial position, v 0 is
the initial velocity, u is n-dimensional vector of agent control.
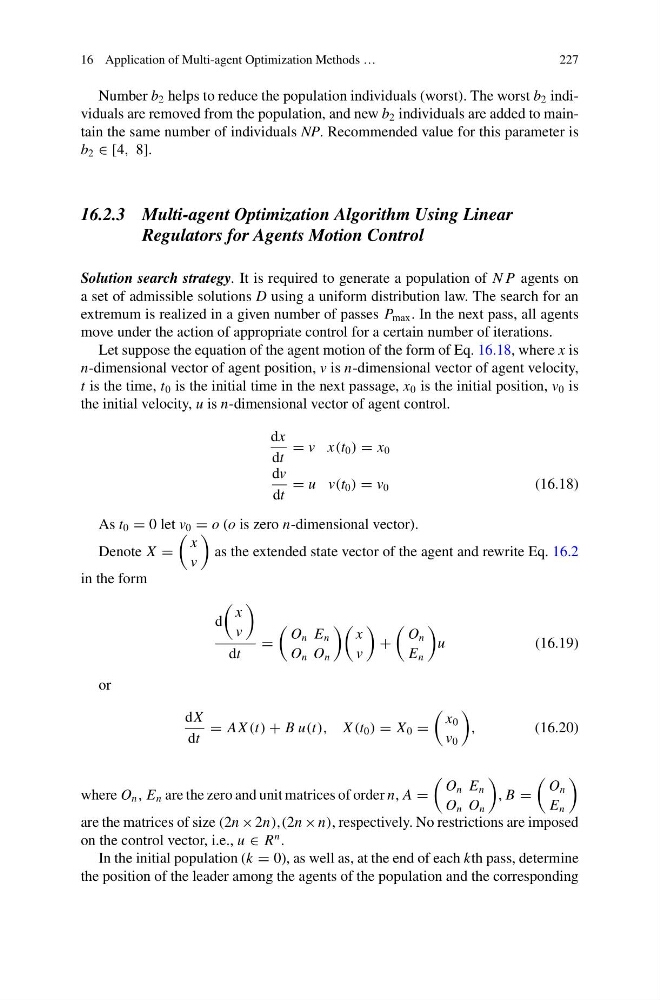
dx
dt
= v x(t 0 ) = x 0
dv
dt
= u v(t 0 ) = v 0
(16.18)
As t 0 = 0 let v 0 = o (o is zero n-dimensional vector).
Denote X =
x
v
as the extended state vector of the agent and rewrite Eq. 16.2
in the form
d
x
v
dt
=
O n E n
O n O n
x
v
+
O n
E n
u
(16.19)
or
dX
dt
= AX (t) + B u(t), X (t 0 ) = X 0 =
x 0
v 0
,
(16.20)
where O n , E n are the zero and unit matrices of order n, A =
O n E n
O n O n
, B =
O n
E n
are the matrices of size (2n × 2n),(2n × n), respectively. No restrictions are imposed
on the control vector, i.e., u ∈ R
n .
In the initial population (k = 0), as well as, at the end of each kth pass, determine
the position of the leader among the agents of the population and the corresponding