

7.1 Principles of Dynamic Similitude
253
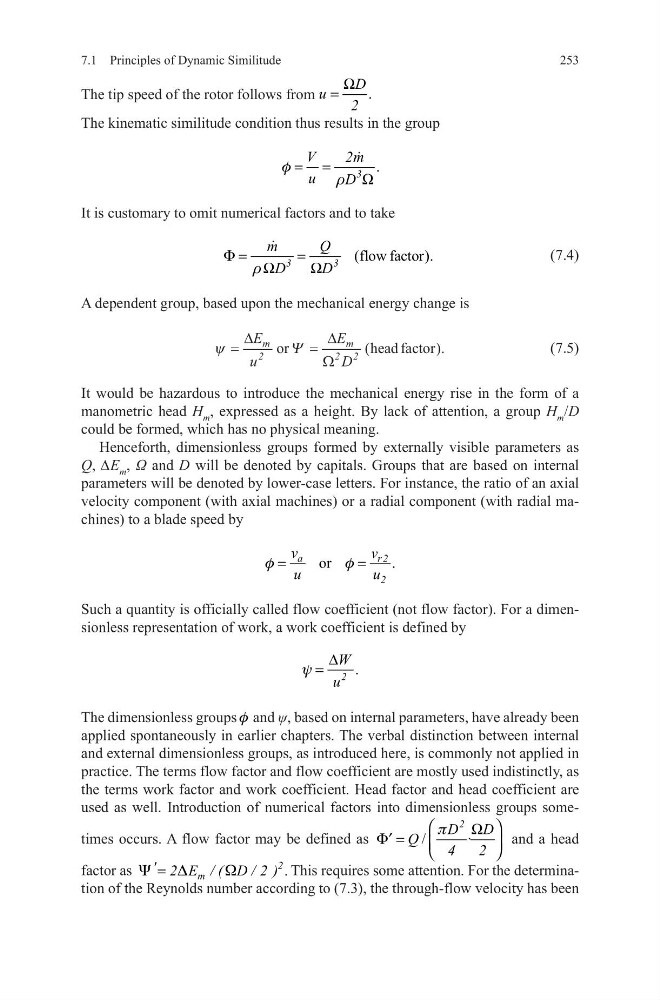
The tip speed of the rotor follows from
.
D
u
2
Ω
=
The kinematic similitude condition thus results in the group
It is customary to omit numerical factors and to take
(7.4)
A dependent group, based upon the mechanical energy change is
(7.5)
It would be hazardous to introduce the mechanical energy rise in the form of a
manometric head H m , expressed as a height. By lack of attention, a group H m /D
could be formed, which has no physical meaning.
Henceforth, dimensionless groups formed by externally visible parameters as
Q, ∆E m , Ω and D will be denoted by capitals. Groups that are based on internal
parameters will be denoted by lower-case letters. For instance, the ratio of an axial
velocity component (with axial machines) or a radial component (with radial machines) to a blade speed by
Such a quantity is officially called flow coefficient (not flow factor). For a dimensionless representation of work, a work coefficient is defined by
The dimensionless groups f and ψ, based on internal parameters, have already been
applied spontaneously in earlier chapters. The verbal distinction between internal
and external dimensionless groups, as introduced here, is commonly not applied in
practice. The terms flow factor and flow coefficient are mostly used indistinctly, as
the terms work factor and work coefficient. Head factor and head coefficient are
used as well. Introduction of numerical factors into dimensionless groups sometimes occurs. A flow factor may be defined as
/
·
2
D
D
Q
4
2
p
F
Ω
=
′
and a head
factor as
2
m
' 2 E / ( D / 2 ) .
Y
D
W
=
This requires some attention. For the determination of the Reynolds number according to (7.3), the through-flow velocity has been
.
3
V
2m
u
D
f
r
= =
Ω
(flow factor).
3
3
m
Q
D
D
F
r
=
=
Ω
Ω
ψ =
=
∆
∆
Ω
E
u
E
D
m
m
2
2 2
or
head factor
Ψ
(
) .
or
.
a
r2
2
v
v
u
u
f
f
=
=
.
2
W
u
y
∆
=