

352
9 Topologic Optimization of Vibrations of Size-Dependent Beams
E (ρ e ) =
ρ e
1 + R E (1 − ρ e )
E 0 ,
(9.31)
β (ρ e ) =
ρ e
1 + R β (1 − ρ e )
E 0 α 0 ,
(9.32)
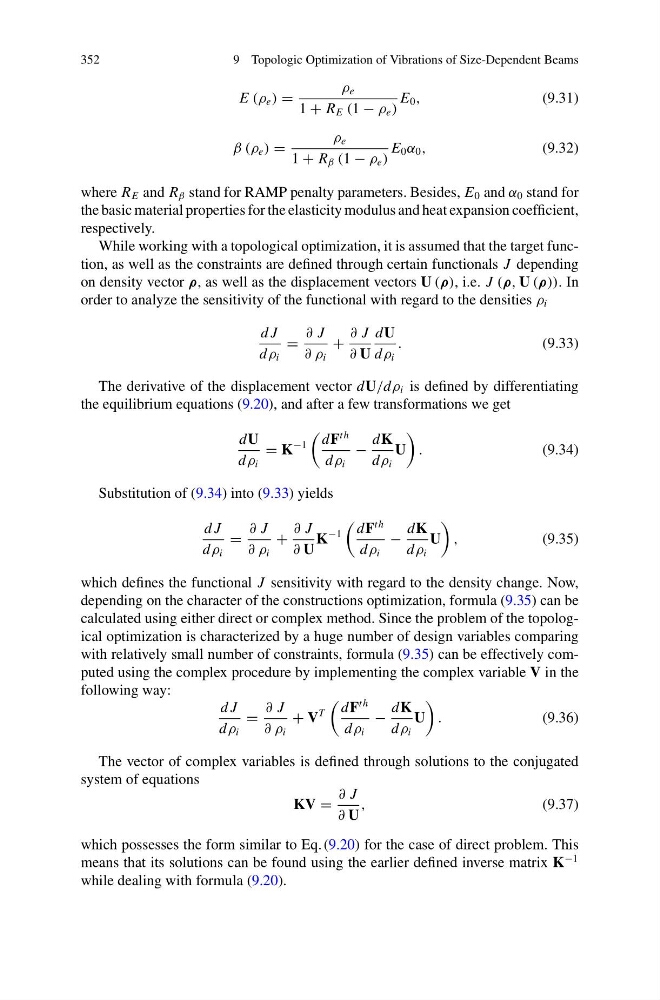
where R E and R β stand for RAMP penalty parameters. Besides, E 0 and α 0 stand for
the basic material properties for the elasticity modulus and heat expansion coefficient,
respectively.
While working with a topological optimization, it is assumed that the target function, as well as the constraints are defined through certain functionals J depending
on density vector ρ, as well as the displacement vectors U (ρ), i.e. J (ρ, U (ρ)). In
order to analyze the sensitivity of the functional with regard to the densities ρ i
d J
dρ i
=
∂ J
∂ ρ i
+
∂ J
∂ U
dU
dρ i
.
(9.33)
The derivative of the displacement vector dU/dρ i is defined by differentiating
the equilibrium equations (9.20), and after a few transformations we get
dU
dρ i
= K
−1
dF
th
dρ i
−
dK
dρ i
U
.
(9.34)
Substitution of (9.34) into (9.33) yields
d J
dρ i
=
∂ J
∂ ρ i
+
∂ J
∂ U
K
−1
dF
th
dρ i
−
dK
dρ i
U
,
(9.35)
which defines the functional J sensitivity with regard to the density change. Now,
depending on the character of the constructions optimization, formula (9.35) can be
calculated using either direct or complex method. Since the problem of the topological optimization is characterized by a huge number of design variables comparing
with relatively small number of constraints, formula (9.35) can be effectively computed using the complex procedure by implementing the complex variable V in the
following way:
d J
dρ i
=
∂ J
∂ ρ i
+ V
T
dF
th
dρ i
−
dK
dρ i
U
.
(9.36)
The vector of complex variables is defined through solutions to the conjugated
system of equations
KV =
∂ J
∂ U
,
(9.37)
which possesses the form similar to Eq. (9.20) for the case of direct problem. This
means that its solutions can be found using the earlier defined inverse matrix K
−1
while dealing with formula (9.20).