

The method of inverse iterations can be extended to yield also higher
eigen-values and eigen-vectors (k j , u j ), j = 2, 3, …. However, for that purpose the
method of subspace iteration (Bathe and Wilson 1976) is more efficient and stable.
2.3 The Differential EVP
Algebraic EVPs, as described above, are defined in terms of matrices and vectors.
Differential EVPs, to be considered here, are characterized by differential operators,
continuous functions, and boundary conditions. Eigenvalues appear in either type
of EVP. Though differential EVPs generally have infinitely many eigenvalues,
whereas algebraic EVPs have only a finite number.
2.3.1 Mathematical Form
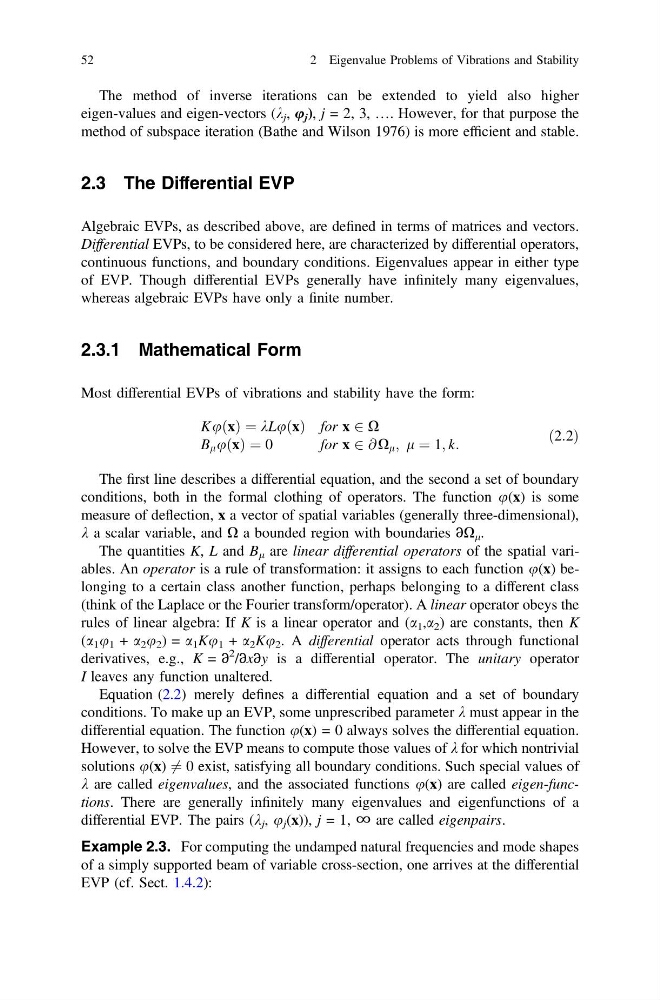
Most differential EVPs of vibrations and stability have the form:
KuðxÞ ¼ kLuðxÞ for x 2 X
B l uðxÞ ¼ 0
for x 2 @ X l ; l ¼ 1; k:
ð2:2Þ
The first line describes a differential equation, and the second a set of boundary
conditions, both in the formal clothing of operators. The function u(x) is some
measure of deflection, x a vector of spatial variables (generally three-dimensional),
k a scalar variable, and X a bounded region with boundaries ∂X l .
The quantities K, L and B l are linear differential operators of the spatial variables. An operator is a rule of transformation: it assigns to each function u(x) belonging to a certain class another function, perhaps belonging to a different class
(think of the Laplace or the Fourier transform/operator). A linear operator obeys the
rules of linear algebra: If K is a linear operator and (a 1 ,a 2 ) are constants, then K
(a 1 u 1 + a 2 u 2 ) = a 1 Ku 1 + a 2 Ku 2 . A differential operator acts through functional
derivatives, e.g., K = ∂
2 /∂x∂y is a differential operator. The unitary operator
I leaves any function unaltered.
Equation (2.2) merely defines a differential equation and a set of boundary
conditions. To make up an EVP, some unprescribed parameter k must appear in the
differential equation. The function u(x) = 0 always solves the differential equation.
However, to solve the EVP means to compute those values of k for which nontrivial
solutions u(x) 6 ¼ 0 exist, satisfying all boundary conditions. Such special values of
k are called eigenvalues, and the associated functions u(x) are called eigen-functions. There are generally infinitely many eigenvalues and eigenfunctions of a
differential EVP. The pairs (k j , u j (x)), j = 1, ∞ are called eigenpairs.
Example 2.3. For computing the undamped natural frequencies and mode shapes
of a simply supported beam of variable cross-section, one arrives at the differential
EVP (cf. Sect. 1.4.2):
52
2 Eigenvalue Problems of Vibrations and Stability