

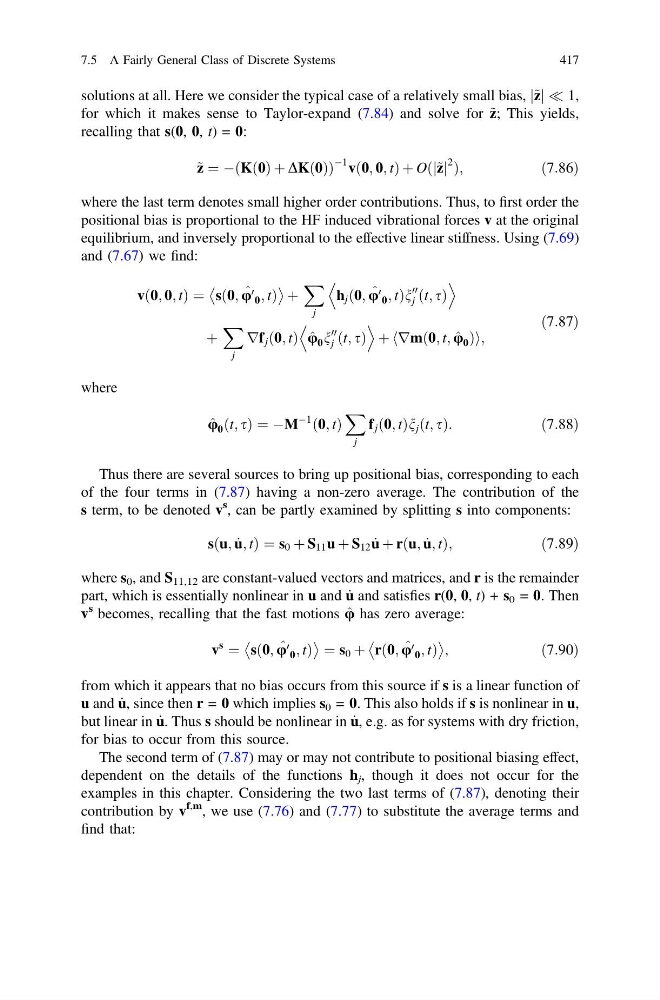
solutions at all. Here we consider the typical case of a relatively small bias, ~ z
j j ( 1,
for which it makes sense to Taylor-expand (7.84) and solve for ~ z; This yields,
recalling that s(0, 0, t) = 0:
~ z ¼ À Kð0Þ þ DKð0Þ
ð
Þ
À1 vð0; 0; tÞ þ Oðj~ zj
2 Þ;
ð7:86Þ
where the last term denotes small higher order contributions. Thus, to first order the
positional bias is proportional to the HF induced vibrational forces v at the original
equilibrium, and inversely proportional to the effective linear stiffness. Using (7.69)
and (7.67) we find:
vð0; 0; tÞ ¼ sð0; ^
u 0 0 ; tÞ
þ
X
j
h j ð0; ^
u 0 0 ; tÞn
00
j ðt; sÞ
D
E
þ
X
j
rf j ð0; tÞ ^
u 0 n
00
j ðt; sÞ
D
E
þ rmð0; t; ^
u 0 Þ
h
i ;
ð7:87Þ
where
^
u 0 ðt; sÞ ¼ ÀM
À1
ð0; tÞ
X
j
f j ð0; tÞn j ðt; sÞ:
ð7:88Þ
Thus there are several sources to bring up positional bias, corresponding to each
of the four terms in (7.87) having a non-zero average. The contribution of the
s term, to be denoted v
s , can be partly examined by splitting s into components:
sðu; _
u; tÞ ¼ s 0 þ S 11 u þ S 12 _
u þ rðu; _
u; tÞ;
ð7:89Þ
where s 0 , and S 11,12 are constant-valued vectors and matrices, and r is the remainder
part, which is essentially nonlinear in u and _
u and satisfies r(0, 0, t) + s 0 = 0. Then
v
s becomes, recalling that the fast motions ^
u has zero average:
v
s
¼ sð0; ^
u 0 0 ; tÞ
¼ s 0 þ rð0; ^
u 0 0 ; tÞ
;
ð7:90Þ
from which it appears that no bias occurs from this source if s is a linear function of
u and _
u, since then r = 0 which implies s 0 = 0. This also holds if s is nonlinear in u,
but linear in _
u. Thus s should be nonlinear in _
u, e.g. as for systems with dry friction,
for bias to occur from this source.
The second term of (7.87) may or may not contribute to positional biasing effect,
dependent on the details of the functions h j , though it does not occur for the
examples in this chapter. Considering the two last terms of (7.87), denoting their
contribution by v
f,m , we use (7.76) and (7.77) to substitute the average terms and
find that:
7.5 A Fairly General Class of Discrete Systems
417