

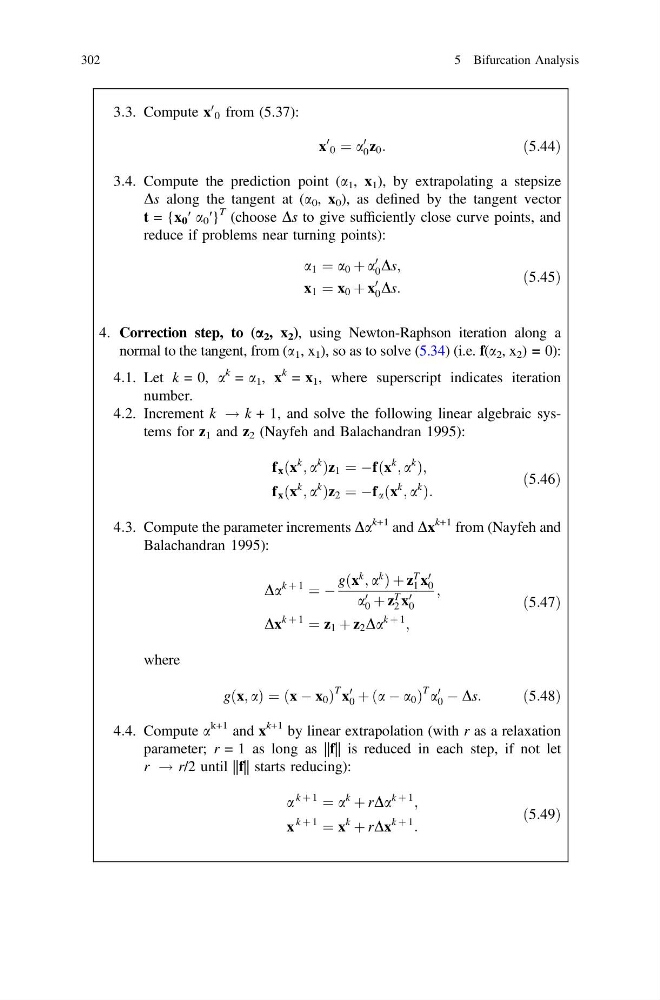
3:3. Compute x
0
0 from (5.37):
x
0
0 ¼ a
0
0 z 0 :
ð5:44Þ
3:4. Compute the prediction point (a 1 , x 1 ), by extrapolating a stepsize
Ds along the tangent at (a 0 , x 0 ), as defined by the tangent vector
t = {x 0 ′ a 0 ′}
T (choose Ds to give sufficiently close curve points, and
reduce if problems near turning points):
a 1 ¼ a 0 þ a
0
0 Ds;
x 1 ¼ x 0 þ x
0
0 Ds:
ð5:45Þ
4. Correction step, to (a 2 , x 2 ), using Newton-Raphson iteration along a
normal to the tangent, from (a 1 , x 1 ), so as to solve (5.34) (i.e. f(a 2 , x 2 ) = 0):
4:1. Let k = 0, a
k = a 1 , x
k = x 1 , where superscript indicates iteration
number.
4:2. Increment k ! k + 1, and solve the following linear algebraic systems for z 1 and z 2 (Nayfeh and Balachandran 1995):
f x ðx
k
; a
k
Þz 1 ¼ Àfðx
k
; a
k
Þ;
f x ðx
k
; a
k
Þz 2 ¼ Àf a ðx
k
; a
k
Þ:
ð5:46Þ
4:3. Compute the parameter increments Da
k+1 and Dx
k+1 from (Nayfeh and
Balachandran 1995):
Da
k þ 1
¼ À
gðx
k
; a
k
Þ þ z
T
1 x
0
0
a 0
0 þ z T
2 x 0
0
;
Dx
k þ 1
¼ z 1 þ z 2 Da
k þ 1
;
ð5:47Þ
where
gðx; aÞ ¼ ðx À x 0 Þ
T x
0
0 þ ða À a 0 Þ
T a
0
0 À Ds:
ð5:48Þ
4:4. Compute a
k+1 and x
k+1 by linear extrapolation (with r as a relaxation
parameter; r = 1 as long as ||f|| is reduced in each step, if not let
r ! r/2 until ||f|| starts reducing):
a
k þ 1
¼ a
k
þ rDa
k þ 1
;
x
k þ 1
¼ x
k
þ rDx
k þ 1
:
ð5:49Þ
302
5 Bifurcation Analysis
0
0 from (5.37):
x
0
0 ¼ a
0
0 z 0 :
ð5:44Þ
3:4. Compute the prediction point (a 1 , x 1 ), by extrapolating a stepsize
Ds along the tangent at (a 0 , x 0 ), as defined by the tangent vector
t = {x 0 ′ a 0 ′}
T (choose Ds to give sufficiently close curve points, and
reduce if problems near turning points):
a 1 ¼ a 0 þ a
0
0 Ds;
x 1 ¼ x 0 þ x
0
0 Ds:
ð5:45Þ
4. Correction step, to (a 2 , x 2 ), using Newton-Raphson iteration along a
normal to the tangent, from (a 1 , x 1 ), so as to solve (5.34) (i.e. f(a 2 , x 2 ) = 0):
4:1. Let k = 0, a
k = a 1 , x
k = x 1 , where superscript indicates iteration
number.
4:2. Increment k ! k + 1, and solve the following linear algebraic systems for z 1 and z 2 (Nayfeh and Balachandran 1995):
f x ðx
k
; a
k
Þz 1 ¼ Àfðx
k
; a
k
Þ;
f x ðx
k
; a
k
Þz 2 ¼ Àf a ðx
k
; a
k
Þ:
ð5:46Þ
4:3. Compute the parameter increments Da
k+1 and Dx
k+1 from (Nayfeh and
Balachandran 1995):
Da
k þ 1
¼ À
gðx
k
; a
k
Þ þ z
T
1 x
0
0
a 0
0 þ z T
2 x 0
0
;
Dx
k þ 1
¼ z 1 þ z 2 Da
k þ 1
;
ð5:47Þ
where
gðx; aÞ ¼ ðx À x 0 Þ
T x
0
0 þ ða À a 0 Þ
T a
0
0 À Ds:
ð5:48Þ
4:4. Compute a
k+1 and x
k+1 by linear extrapolation (with r as a relaxation
parameter; r = 1 as long as ||f|| is reduced in each step, if not let
r ! r/2 until ||f|| starts reducing):
a
k þ 1
¼ a
k
þ rDa
k þ 1
;
x
k þ 1
¼ x
k
þ rDx
k þ 1
:
ð5:49Þ
302
5 Bifurcation Analysis