

the most important concepts. A readable account of this kind is given in Païdoussis
and Semler (1993) (see also Hsu 1983; Li and Païdoussis 1994).
5.5.1 The Center Manifold Theorem
We adopt from Guckenheimer and Holmes (1983) the following formulation for
systems of differential equations having the form _
x = f(x), x(t) 2 R
n :
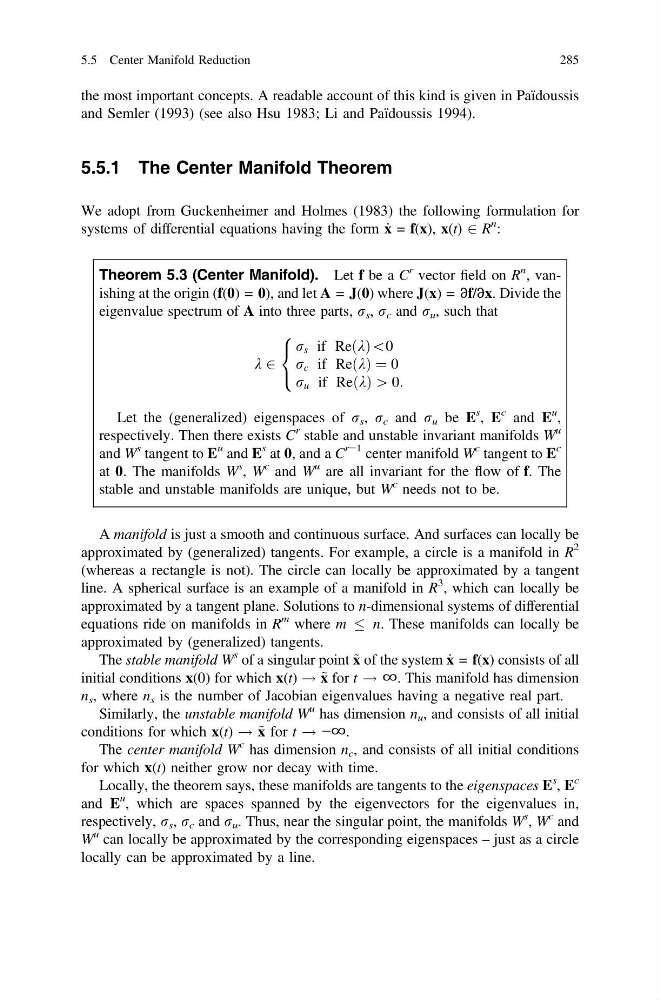
Theorem 5.3 (Center Manifold). Let f be a C
r vector field on R
n , vanishing at the origin (f(0) = 0), and let A = J(0) where J(x) = ∂f/∂x. Divide the
eigenvalue spectrum of A into three parts, r s , r c and r u , such that
k 2
r s if ReðkÞ\0
r c if ReðkÞ ¼ 0
r u if ReðkÞ [ 0:
8
<
:
Let the (generalized) eigenspaces of r s , r c and r u be E
s , E
c and E
u ,
respectively. Then there exists C
r stable and unstable invariant manifolds W
u
and W
s tangent to E
u and E
s at 0, and a C
r−1 center manifold W
c tangent to E
c
at 0. The manifolds W
s
, W
c and W
u are all invariant for the flow of f. The
stable and unstable manifolds are unique, but W
c needs not to be.
A manifold is just a smooth and continuous surface. And surfaces can locally be
approximated by (generalized) tangents. For example, a circle is a manifold in R
2
(whereas a rectangle is not). The circle can locally be approximated by a tangent
line. A spherical surface is an example of a manifold in R
3 , which can locally be
approximated by a tangent plane. Solutions to n-dimensional systems of differential
equations ride on manifolds in R
m where m
n. These manifolds can locally be
approximated by (generalized) tangents.
The stable manifold W
s of a singular point ~ x of the system _
x = f(x) consists of all
initial conditions x(0) for which x(t) ! ~ x for t ! ∞. This manifold has dimension
n s , where n s is the number of Jacobian eigenvalues having a negative real part.
Similarly, the unstable manifold W
u has dimension n u , and consists of all initial
conditions for which x(t) ! ~ x for t ! −∞.
The center manifold W
c has dimension n c , and consists of all initial conditions
for which x(t) neither grow nor decay with time.
Locally, the theorem says, these manifolds are tangents to the eigenspaces E
s
, E
c
and E
u , which are spaces spanned by the eigenvectors for the eigenvalues in,
respectively, r s , r c and r u . Thus, near the singular point, the manifolds W
s , W
c and
W
u can locally be approximated by the corresponding eigenspaces – just as a circle
locally can be approximated by a line.
5.5 Center Manifold Reduction
285