

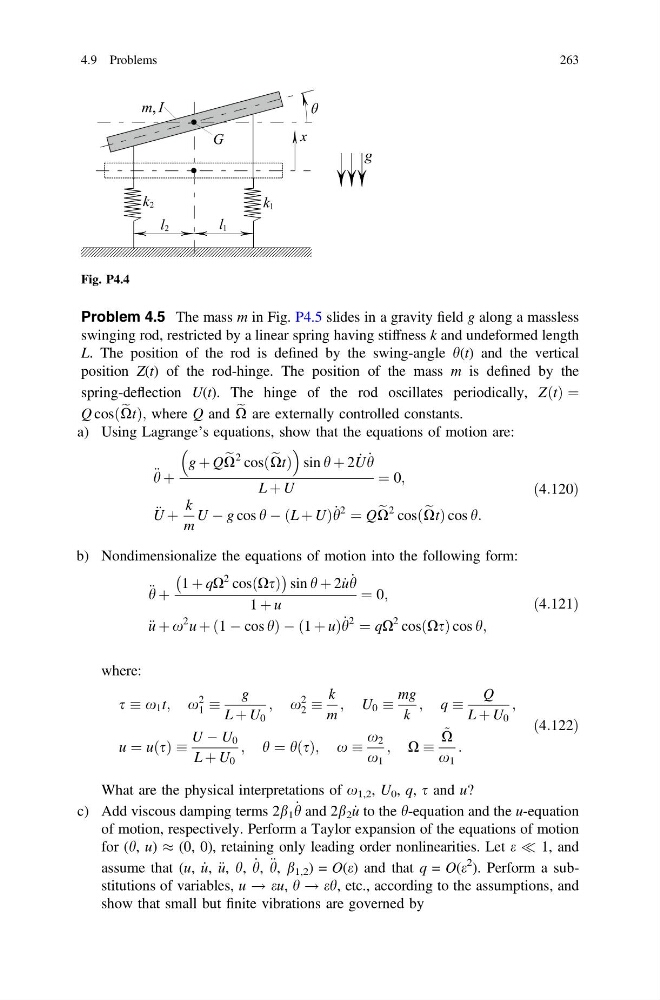
Fig. P4.4
Problem 4.5 The mass m in Fig. P4.5 slides in a gravity field g along a massless
swinging rod, restricted by a linear spring having stiffness k and undeformed length
L. The position of the rod is defined by the swing-angle h(t) and the vertical
position Z(t) of the rod-hinge. The position of the mass m is defined by the
spring-deflection U(t). The hinge of the rod oscillates periodically, ZðtÞ ¼
Q cosð e
XtÞ; where Q and e
X are externally controlled constants.
a) Using Lagrange’s equations, show that the equations of motion are:
€ h þ
g þ Q e
X
2 cosð e
XtÞ
sin h þ 2 _
U _
h
L þ U
¼ 0;
€
U þ
k
m
U À g cos h À ðL þ UÞ _
h
2
¼ Q e
X
2 cosð e
XtÞ cos h:
ð4:120Þ
b) Nondimensionalize the equations of motion into the following form:
€ h þ
1 þ qX
2 cosðXsÞ
À
Á
sin h þ 2 _
u _
h
1 þ u
¼ 0;
€ u þ x
2 u þ ð1 À cos hÞ À ð1 þ uÞ _
h
2
¼ qX
2 cosðXsÞ cos h;
ð4:121Þ
where:
s x 1 t; x
2
1
g
L þ U 0
; x
2
2
k
m
; U 0
mg
k
; q
Q
L þ U 0
;
u ¼ uðsÞ
U À U 0
L þ U 0
; h ¼ hðsÞ; x
x 2
x 1
; X
~
X
x 1
:
ð4:122Þ
What are the physical interpretations of x 1,2 , U 0 , q, s and u?
c) Add viscous damping terms 2b 1 _
h and 2b 2 _
u to the h-equation and the u-equation
of motion, respectively. Perform a Taylor expansion of the equations of motion
for (h, u) % (0, 0), retaining only leading order nonlinearities. Let e ( 1, and
assume that (u, _
u, € u, h, _
h, € h, b 1,2 ) = O(e) and that q = O(e
2 ). Perform a substitutions of variables, u ! eu, h ! eh, etc., according to the assumptions, and
show that small but finite vibrations are governed by
4.9 Problems
263