

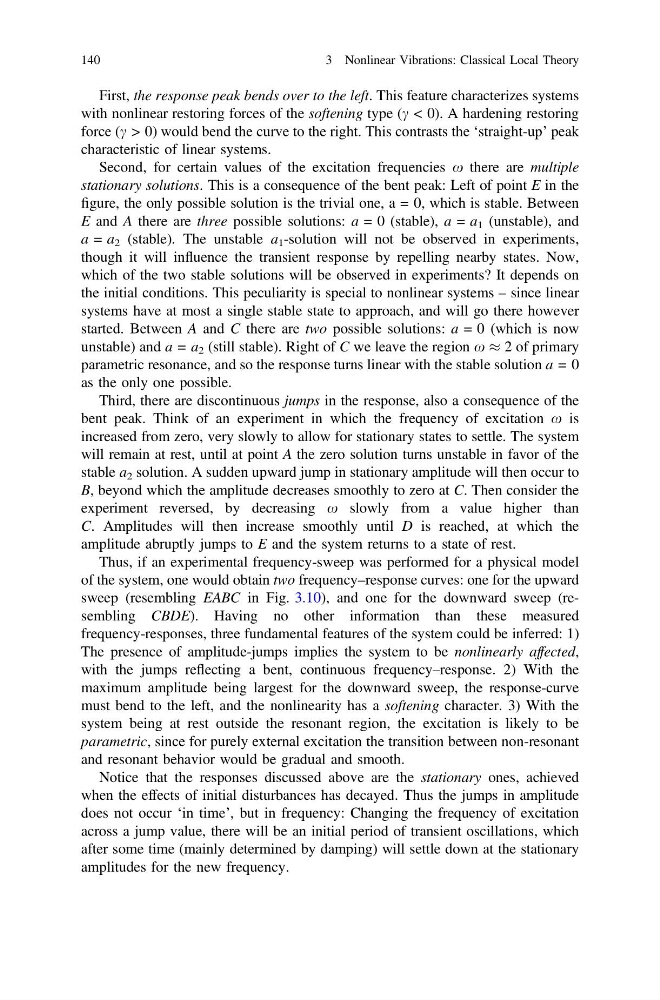
First, the response peak bends over to the left. This feature characterizes systems
with nonlinear restoring forces of the softening type (c < 0). A hardening restoring
force (c > 0) would bend the curve to the right. This contrasts the ‘straight-up’ peak
characteristic of linear systems.
Second, for certain values of the excitation frequencies x there are multiple
stationary solutions. This is a consequence of the bent peak: Left of point E in the
figure, the only possible solution is the trivial one, a = 0, which is stable. Between
E and A there are three possible solutions: a = 0 (stable), a = a 1 (unstable), and
a = a 2 (stable). The unstable a 1 -solution will not be observed in experiments,
though it will influence the transient response by repelling nearby states. Now,
which of the two stable solutions will be observed in experiments? It depends on
the initial conditions. This peculiarity is special to nonlinear systems – since linear
systems have at most a single stable state to approach, and will go there however
started. Between A and C there are two possible solutions: a = 0 (which is now
unstable) and a = a 2 (still stable). Right of C we leave the region x % 2 of primary
parametric resonance, and so the response turns linear with the stable solution a = 0
as the only one possible.
Third, there are discontinuous jumps in the response, also a consequence of the
bent peak. Think of an experiment in which the frequency of excitation x is
increased from zero, very slowly to allow for stationary states to settle. The system
will remain at rest, until at point A the zero solution turns unstable in favor of the
stable a 2 solution. A sudden upward jump in stationary amplitude will then occur to
B, beyond which the amplitude decreases smoothly to zero at C. Then consider the
experiment reversed, by decreasing x slowly from a value higher than
C. Amplitudes will then increase smoothly until D is reached, at which the
amplitude abruptly jumps to E and the system returns to a state of rest.
Thus, if an experimental frequency-sweep was performed for a physical model
of the system, one would obtain two frequency–response curves: one for the upward
sweep (resembling EABC in Fig. 3.10), and one for the downward sweep (resembling CBDE). Having no other information than these measured
frequency-responses, three fundamental features of the system could be inferred: 1)
The presence of amplitude-jumps implies the system to be nonlinearly affected,
with the jumps reflecting a bent, continuous frequency–response. 2) With the
maximum amplitude being largest for the downward sweep, the response-curve
must bend to the left, and the nonlinearity has a softening character. 3) With the
system being at rest outside the resonant region, the excitation is likely to be
parametric, since for purely external excitation the transition between non-resonant
and resonant behavior would be gradual and smooth.
Notice that the responses discussed above are the stationary ones, achieved
when the effects of initial disturbances has decayed. Thus the jumps in amplitude
does not occur ‘in time’, but in frequency: Changing the frequency of excitation
across a jump value, there will be an initial period of transient oscillations, which
after some time (mainly determined by damping) will settle down at the stationary
amplitudes for the new frequency.
140
3 Nonlinear Vibrations: Classical Local Theory