

3.4.2 The Phase Plane
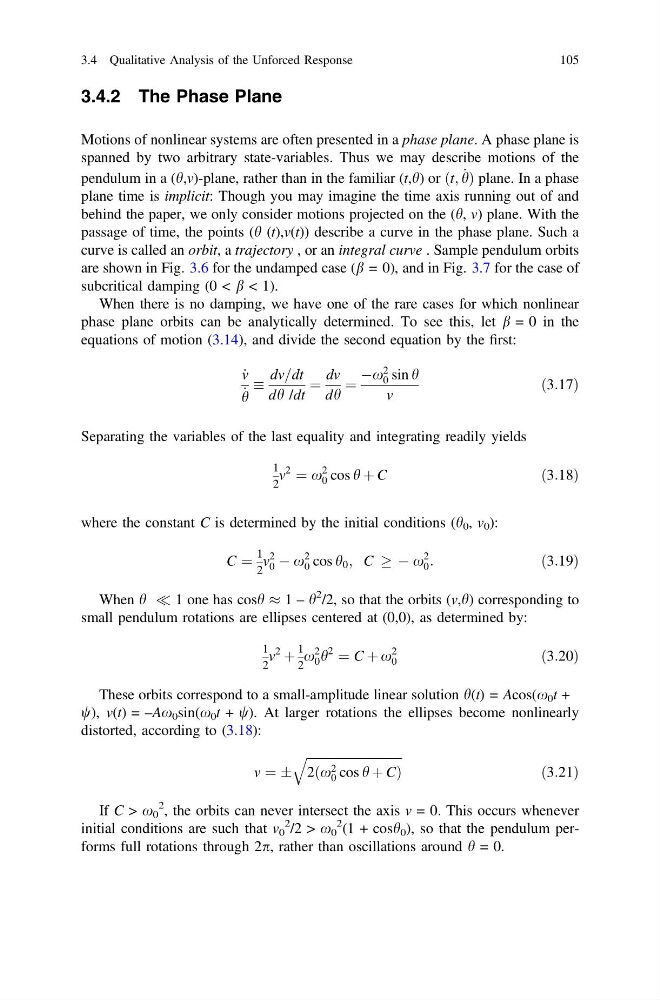
Motions of nonlinear systems are often presented in a phase plane. A phase plane is
spanned by two arbitrary state-variables. Thus we may describe motions of the
pendulum in a (h,v)-plane, rather than in the familiar (t,h) or ðt; _
hÞ plane. In a phase
plane time is implicit: Though you may imagine the time axis running out of and
behind the paper, we only consider motions projected on the (h, v) plane. With the
passage of time, the points (h (t),v(t)) describe a curve in the phase plane. Such a
curve is called an orbit, a trajectory , or an integral curve . Sample pendulum orbits
are shown in Fig. 3.6 for the undamped case (b = 0), and in Fig. 3.7 for the case of
subcritical damping (0 < b < 1).
When there is no damping, we have one of the rare cases for which nonlinear
phase plane orbits can be analytically determined. To see this, let b = 0 in the
equations of motion (3.14), and divide the second equation by the first:
_
v
_
h
dv=dt
dh /dt
¼
dv
dh
¼
Àx
2
0 sin h
v
ð3:17Þ
Separating the variables of the last equality and integrating readily yields
1
2
v
2
¼ x
2
0 cos h þ C
ð3:18Þ
where the constant C is determined by the initial conditions (h 0 , v 0 ):
C ¼
1
2
v
2
0 À x
2
0 cos h 0 ; C ! À x
2
0 :
ð3:19Þ
When h ( 1 one has cosh % 1 – h
2 /2, so that the orbits (v,h) corresponding to
small pendulum rotations are ellipses centered at (0,0), as determined by:
1
2
v
2
þ
1
2
x
2
0 h
2
¼ C þ x
2
0
ð3:20Þ
These orbits correspond to a small-amplitude linear solution h(t) = Acos(x 0 t +
w), v(t) = –Ax 0 sin(x 0 t + w). At larger rotations the ellipses become nonlinearly
distorted, according to (3.18):
v ¼ Æ
ffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffi ffi
2ðx 2
0 cos h þ CÞ
q
ð3:21Þ
If C > x 0
2 , the orbits can never intersect the axis v = 0. This occurs whenever
initial conditions are such that v 0
2 /2 > x 0
2 (1 + cosh 0 ), so that the pendulum performs full rotations through 2p, rather than oscillations around h = 0.
3.4 Qualitative Analysis of the Unforced Response
105