

3.4 Strain Field
49
2
0
ε αβ =
0
ϕ αβ +
0
ϕ βα +
0
ϕ 3α
0
ϕ 3β +
0
ϕ
δ
α
0
ϕ δβ ,
(3.83)
2
1
ε αβ =
1
ϕ αβ − b
λ
β
0
ϕ λα +
1
ϕ βα − b
δ
α
0
ϕ δβ
+
0
ϕ 3α
1
ϕ 3β +
1
ϕ 3α
0
ϕ 3β +
0
ϕ
δ
α
1
ϕ δβ +
1
ϕ
δ
α
0
ϕ δβ ,
(3.84)
2
2
ε αβ = −b
λ
β
1
ϕ λα − b
δ
α
1
ϕ δβ +
1
ϕ 3α
1
ϕ 3β +
1
ϕ
δ
α
1
ϕ δβ ,
(3.85)
2
0
ε α3 =
1
v α +
0
ϕ 3α +
0
ϕ
δ
α
1
v δ +
0
ϕ 3α
1
v 3 ,
(3.86)
2
1
ε α3 =
1
ϕ 3α − b
δ
α
1
v δ +
1
ϕ
δ
α
1
v δ +
1
ϕ 3α
1
v 3 ,
(3.87)
2
0
ε 33 = 2
1
v 3 + a
λδ 1
v λ
1
v δ + (
1
v 3 )
2
.
(3.88)
3.5 Shell Theories
In Sect. 3.4, the fully geometrically nonlinear strain-displacement relations are discussed. In the framework of FOSD hypothesis, six parameters are introduced. For
the simplified nonlinear or linear strain-displacement relations, the six parameters
are reduced to five parameters. The definitions of linear and nonlinear shell theories
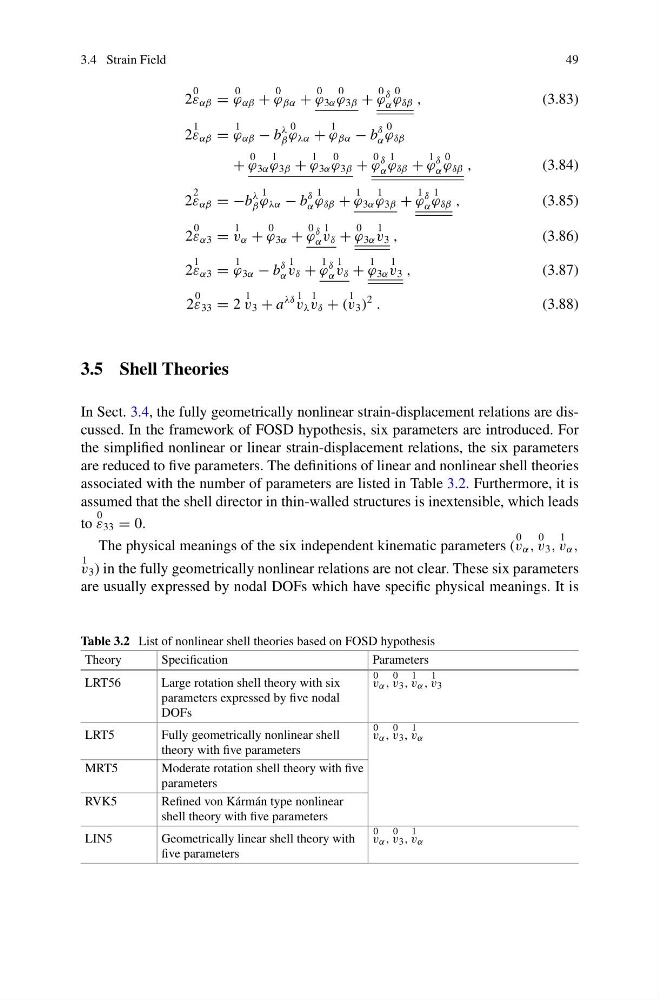
associated with the number of parameters are listed in Table 3.2. Furthermore, it is
assumed that the shell director in thin-walled structures is inextensible, which leads
to
0
ε 33 = 0.
The physical meanings of the six independent kinematic parameters (
0
v α ,
0
v 3 ,
1
v α ,
1
v 3 ) in the fully geometrically nonlinear relations are not clear. These six parameters
are usually expressed by nodal DOFs which have specific physical meanings. It is
Table 3.2 List of nonlinear shell theories based on FOSD hypothesis
Theory
Specification
Parameters
LRT56
Large rotation shell theory with six
parameters expressed by five nodal
DOFs
0
v α ,
0
v 3 ,
1
v α ,
1
v 3
LRT5
Fully geometrically nonlinear shell
theory with five parameters
0
v α ,
0
v 3 ,
1
v α
MRT5
Moderate rotation shell theory with five
parameters
RVK5
Refined von Kármán type nonlinear
shell theory with five parameters
LIN5
Geometrically linear shell theory with
five parameters
0
v α ,
0
v 3 ,
1
v α