

3.2 Mathematical Preliminaries
41
3.2.3 Base Vectors and Metric Tensor at Mid-surface
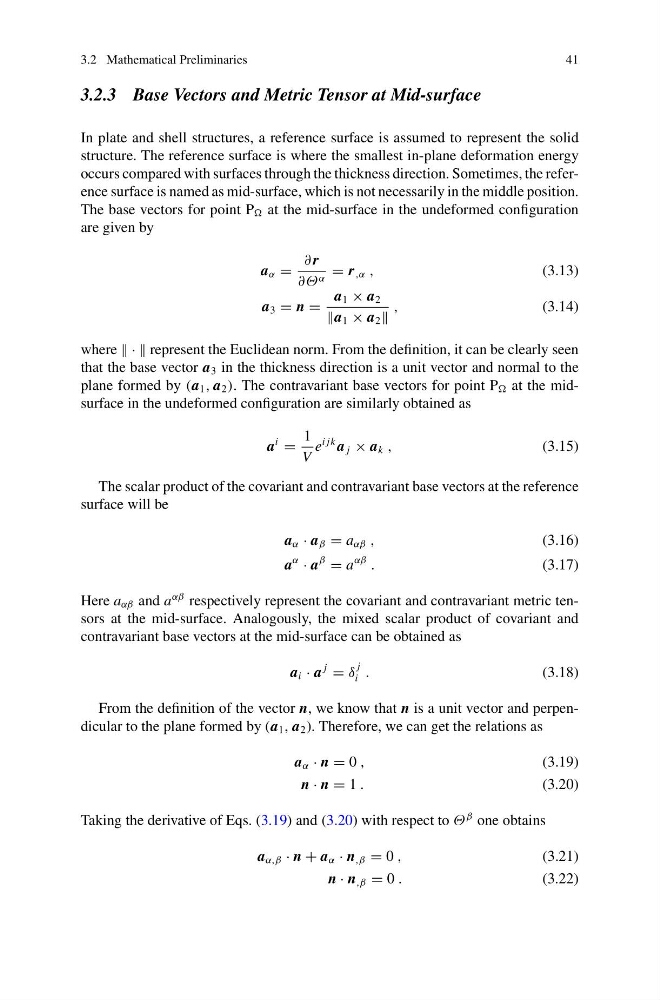
In plate and shell structures, a reference surface is assumed to represent the solid
structure. The reference surface is where the smallest in-plane deformation energy
occurs compared with surfaces through the thickness direction. Sometimes, the reference surface is named as mid-surface, which is not necessarily in the middle position.
The base vectors for point P at the mid-surface in the undeformed configuration
are given by
a α =
∂ r
∂Θ α = r ,α ,
(3.13)
a 3 = n =
a 1 × a 2
a 1 × a 2
,
(3.14)
where · · represent the Euclidean norm. From the definition, it can be clearly seen
that the base vector a 3 in the thickness direction is a unit vector and normal to the
plane formed by (a 1 , a 2 ). The contravariant base vectors for point P at the midsurface in the undeformed configuration are similarly obtained as
a
i
=
1
V
e
i jk a j × a k ,
(3.15)
The scalar product of the covariant and contravariant base vectors at the reference
surface will be
a α · a β = a αβ ,
(3.16)
a
α
· a
β
= a
αβ
.
(3.17)
Here a αβ and a
αβ respectively represent the covariant and contravariant metric tensors at the mid-surface. Analogously, the mixed scalar product of covariant and
contravariant base vectors at the mid-surface can be obtained as
a i · a
j
= δ
j
i .
(3.18)
From the definition of the vector n, we know that n is a unit vector and perpendicular to the plane formed by (a 1 , a 2 ). Therefore, we can get the relations as
a α · n = 0 ,
(3.19)
n · n = 1 .
(3.20)
Taking the derivative of Eqs. (3.19) and (3.20) with respect to Θ
β one obtains
a α,β · n + a α · n ,β = 0 ,
(3.21)
n · n ,β = 0 .
(3.22)