

90
5 Finite Element Formulations
2
0 δW ext =
V
2
0 δu
T f b dV +
2
0 δu
T f s d +
2
0 δu
T f c −
2
0 δφ
T
d −
2
0 δφ
T Q c
= δq
T
F ub + F us + F uc
+ δφ
T
G φs + G φc
,
(5.60)
with
F ub =
V
N
T
u T
T
v Z
T
u f b dV ,
(5.61)
F us =
N
T
u T
T
v Z
T
u f s d ,
(5.62)
F uc = N
T
u T
T
v Z
T
u f c ,
(5.63)
G φs = −
d ,
(5.64)
G φc = − Q c ,
(5.65)
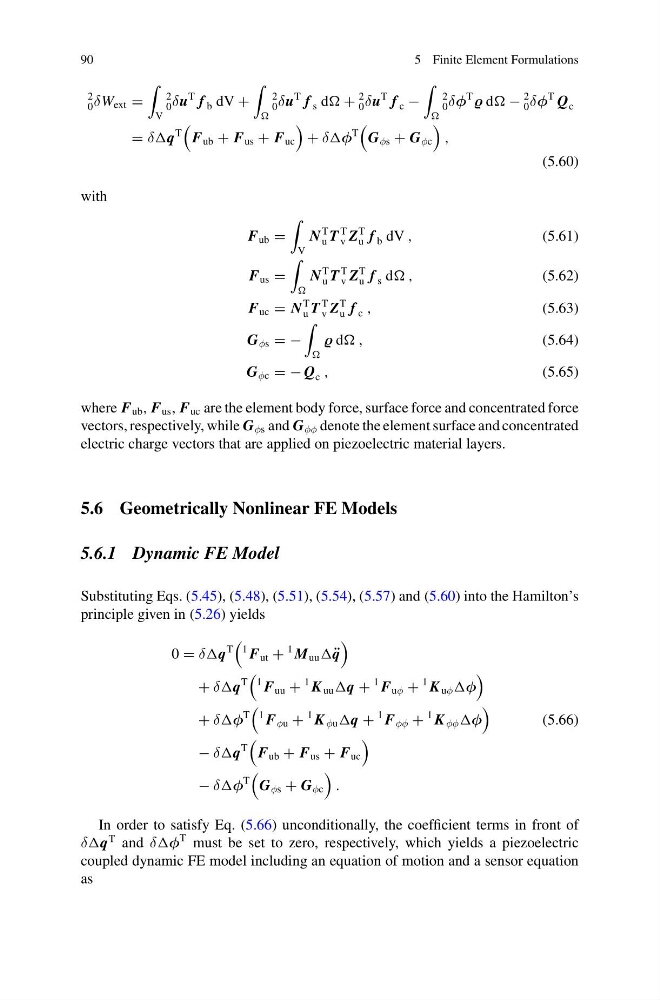
where F ub , F us , F uc are the element body force, surface force and concentrated force
vectors, respectively, while G φs and G φφ denote the element surface and concentrated
electric charge vectors that are applied on piezoelectric material layers.
5.6 Geometrically Nonlinear FE Models
5.6.1 Dynamic FE Model
Substituting Eqs. (5.45), (5.48), (5.51), (5.54), (5.57) and (5.60) into the Hamilton’s
principle given in (5.26) yields
0 = δq
T
1 F ut +
1 M uu ¨
q
+ δq
T
1 F uu +
1 K uu q +
1 F uφ +
1 K uφ φ
+ δφ
T
1 F φu +
1 K φu q +
1 F φφ +
1 K φφ φ
− δq
T
F ub + F us + F uc
− δφ
T
G φs + G φc
.
(5.66)
In order to satisfy Eq. (5.66) unconditionally, the coefficient terms in front of
δq
T and δφ
T must be set to zero, respectively, which yields a piezoelectric
coupled dynamic FE model including an equation of motion and a sensor equation
as