

8.3 Linear Theory for Growing Beams and Plates
415
σ =
E
1 − ν 2
0 + yκ − g
(8.15)
for growth in the x-direction only.
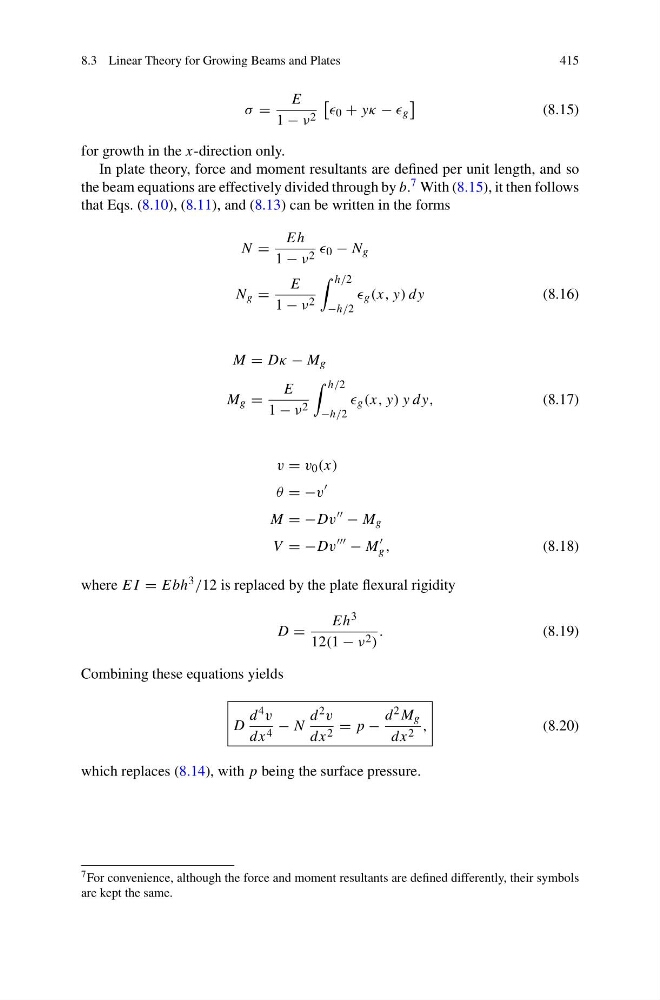
In plate theory, force and moment resultants are defined per unit length, and so
the beam equations are effectively divided through by b. 7 With (8.15), it then follows
that Eqs. (8.10), (8.11), and (8.13) can be written in the forms
N =
Eh
1 − ν 2 0 − N g
N g =
E
1 − ν 2
h/2
−h/2
g (x, y) dy
(8.16)
M = Dκ − M g
M g =
E
1 − ν 2
h/2
−h/2
g (x, y) y dy,
(8.17)
v = v 0 (x)
θ = −v
M = −Dv
− M g
V = −Dv
− M
g ,
(8.18)
where EI = Ebh 3 /12 is replaced by the plate flexural rigidity
D =
Eh 3
12(1 − ν 2 )
.
(8.19)
Combining these equations yields
D
d 4 v
dx 4 − N
d 2 v
dx 2 = p −
d 2 M g
dx 2 ,
(8.20)
which replaces (8.14), with p being the surface pressure.
7 For convenience, although the force and moment resultants are defined differently, their symbols
are kept the same.