

356
7 Remodeling
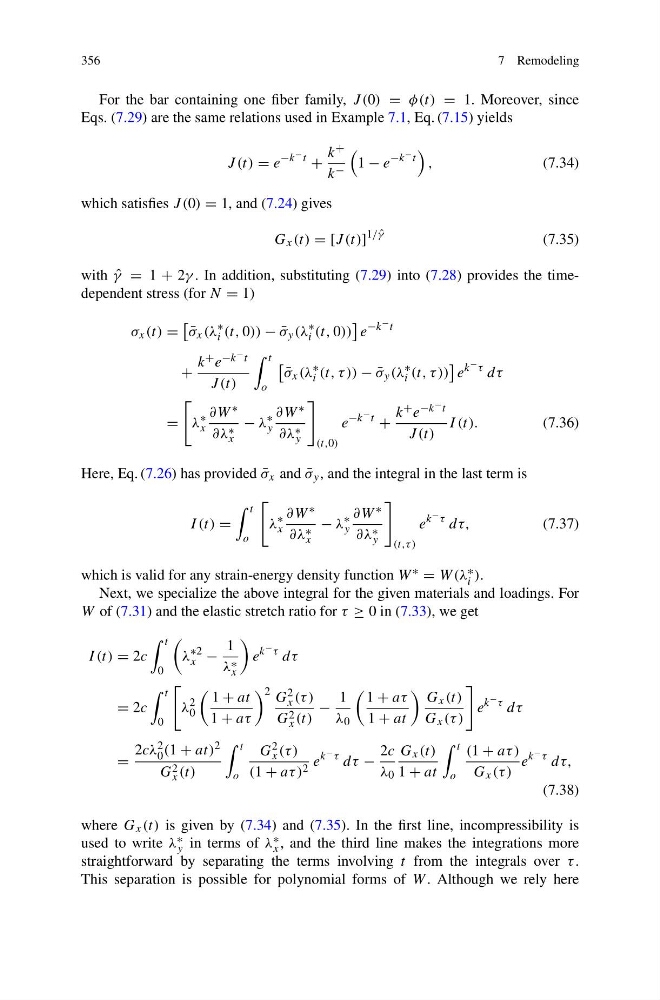
For the bar containing one fiber family, J (0) = φ(t) = 1. Moreover, since
Eqs. (7.29) are the same relations used in Example 7.1, Eq. (7.15) yields
J (t) = e
−k − t
+
k +
k −
1 − e
−k − t
,
(7.34)
which satisfies J (0) = 1, and (7.24) gives
G x (t) = [J (t)]
1/ ˆ
γ
(7.35)
with ˆ
γ = 1 + 2γ . In addition, substituting (7.29) into (7.28) provides the timedependent stress (for N = 1)
σ x (t) =
¯
σ x (λ
∗
i (t, 0)) − ¯
σ y (λ
∗
i (t, 0))
e
−k − t
+
k + e −k − t
J (t)
t
o
¯
σ x (λ
∗
i (t, τ )) − ¯
σ y (λ
∗
i (t, τ ))
e
k − τ dτ
=
λ
∗
x
∂W ∗
∂λ ∗
x
− λ
∗
y
∂W ∗
∂λ ∗
y
(t,0)
e
−k − t
+
k + e −k − t
J (t)
I (t).
(7.36)
Here, Eq. (7.26) has provided ¯
σ x and ¯
σ y , and the integral in the last term is
I (t) =
t
o
λ
∗
x
∂W ∗
∂λ ∗
x
− λ
∗
y
∂W ∗
∂λ ∗
y
(t,τ )
e
k − τ dτ,
(7.37)
which is valid for any strain-energy density function W ∗ = W (λ ∗
i ).
Next, we specialize the above integral for the given materials and loadings. For
W of (7.31) and the elastic stretch ratio for τ ≥ 0 in (7.33), we get
I (t) = 2c
t
0
λ
∗2
x −
1
λ ∗
x
e
k − τ dτ
= 2c
t
0
λ
2
0
1 + at
1 + aτ
2 G 2
x (τ )
G 2
x (t)
−
1
λ 0
1 + aτ
1 + at
G x (t)
G x (τ )
e
k − τ dτ
=
2cλ 2
0 (1 + at) 2
G 2
x (t)
t
o
G 2
x (τ )
(1 + aτ ) 2 e
k − τ dτ −
2c
λ 0
G x (t)
1 + at
t
o
(1 + aτ )
G x (τ )
e
k − τ dτ,
(7.38)
where G x (t) is given by (7.34) and (7.35). In the first line, incompressibility is
used to write λ ∗
y in terms of λ ∗
x , and the third line makes the integrations more
straightforward by separating the terms involving t from the integrals over τ .
This separation is possible for polynomial forms of W . Although we rely here