

106
3 Continuum Mechanics and Nonlinear Elasticity
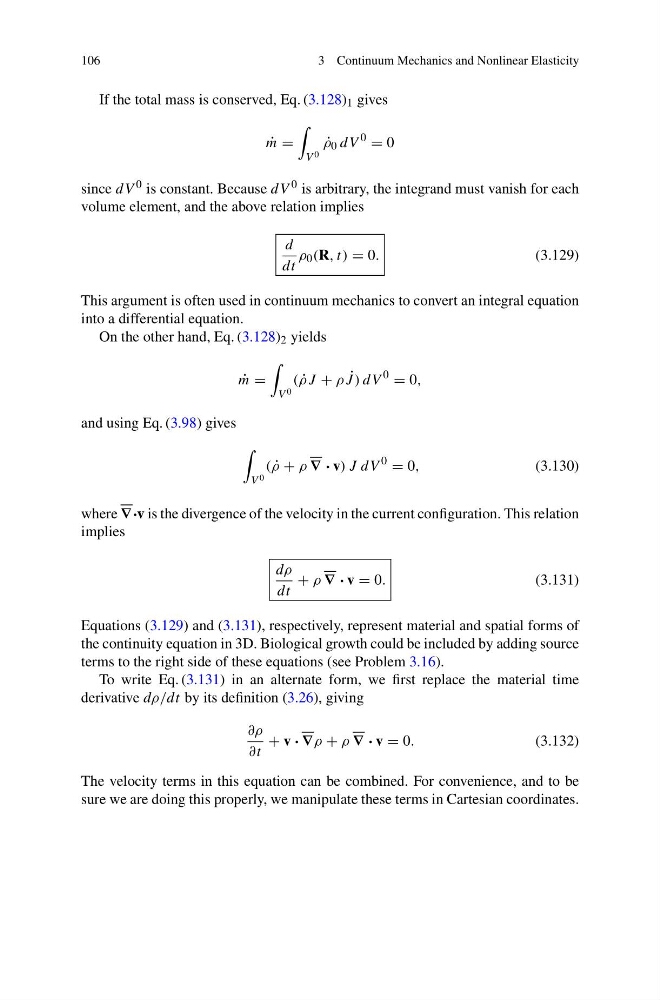
If the total mass is conserved, Eq. (3.128) 1 gives
˙
m =
V 0
˙
ρ 0 dV
0
= 0
since dV 0 is constant. Because dV 0 is arbitrary, the integrand must vanish for each
volume element, and the above relation implies
d
dt
ρ 0 (R, t) = 0.
(3.129)
This argument is often used in continuum mechanics to convert an integral equation
into a differential equation.
On the other hand, Eq. (3.128) 2 yields
˙
m =
V 0
( ˙
ρJ + ρ ˙
J ) dV
0
= 0,
and using Eq. (3.98) gives
V 0
( ˙
ρ + ρ ∇ · v) J dV
0
= 0,
(3.130)
where ∇·v is the divergence of the velocity in the current configuration. This relation
implies
dρ
dt
+ ρ ∇ · v = 0.
(3.131)
Equations (3.129) and (3.131), respectively, represent material and spatial forms of
the continuity equation in 3D. Biological growth could be included by adding source
terms to the right side of these equations (see Problem 3.16).
To write Eq. (3.131) in an alternate form, we first replace the material time
derivative dρ/dt by its definition (3.26), giving
∂ρ
∂t
+ v · ∇ρ + ρ ∇ · v = 0.
(3.132)
The velocity terms in this equation can be combined. For convenience, and to be
sure we are doing this properly, we manipulate these terms in Cartesian coordinates.