

The Central Complex Path Integration Circuit Deployed on an MAV
333
50
100
150
Outbound distance (m)
0
10
20
30
40
Final displacement error (m)
real
flat
bumpy
forest
Furkastrasse
Furkastrasse textured
real - datum
0
50
100
150
Memory cell range estimate (m)
0
20
40
60
80
100
Absolute heading error (°)
Inbound
Outbound
Inbound fit
Outbound fit
Inbound fit - 50m
120
90
60
10
2
Flow field width & height (pixels)
0
2
4
6
8
Final displacement error (m)
0
1 5
3 0
5 0
7 0
Pitch angle w.r.t. gravity (°)
5
10
15
20
Final displacement error (m)
0
1
2
3
4
5
Maximum height offset amplitude (m)
5
10
15
Final displacement error (m)
compensated
uncompensated
a
b
c
d
e
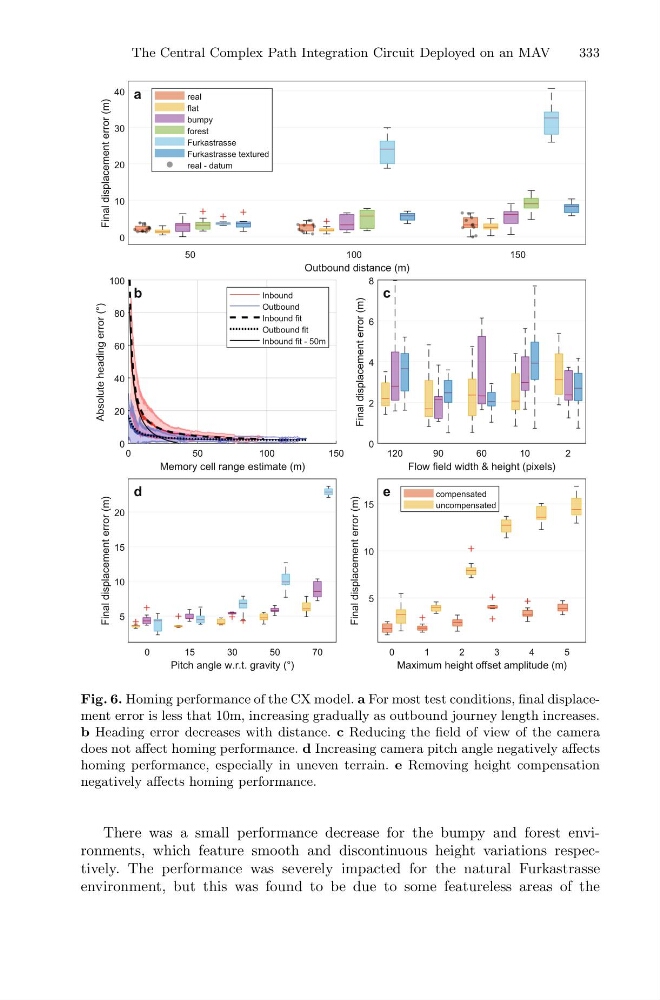
Fig. 6. Homing performance of the CX model. a For most test conditions, final displacement error is less that 10m, increasing gradually as outbound journey length increases.
b Heading error decreases with distance. c Reducing the field of view of the camera
does not affect homing performance. d Increasing camera pitch angle negatively affects
homing performance, especially in uneven terrain. e Removing height compensation
negatively affects homing performance.
There was a small performance decrease for the bumpy and forest environments, which feature smooth and discontinuous height variations respectively. The performance was severely impacted for the natural Furkastrasse
environment, but this was found to be due to some featureless areas of the