

Robotics Application of a Method for Analytically Computing Infinitesimal
109
active neuron in the CPG. This causes the angular velocity to switch signs due to Eq. 12,
leading to a change in direction. G fb for neurons 1 and 2 are represented by the following
piecewise functions
G fb,1 (θ ) =
0, θ < θ FLX
g FB , θ ≥ θ FLX
(14)
G fb,2 (θ ) =
0, θ > θ EXT
g FB , θ ≤ θ EXT
(15)
Where g FB is the maximum feedback conductance, θ FLX is the flexion position trigger
and θ EXT is the extension position trigger. The current model sets θ FLX = 30 degrees
and θ EXT = −10 degrees based on hip angle ranges during locomotion found in [18].
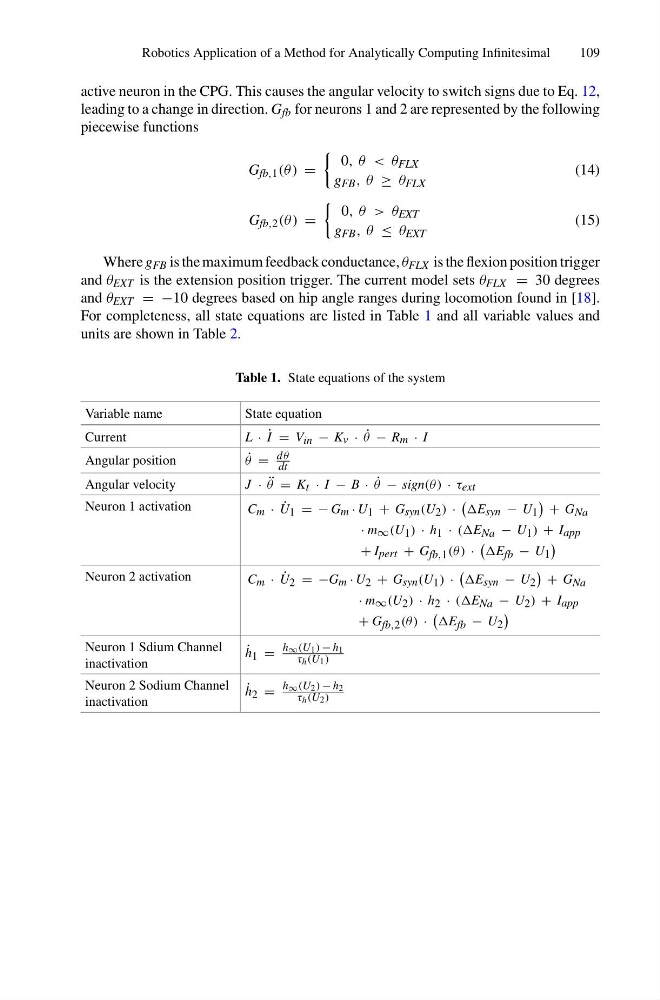
For completeness, all state equations are listed in Table 1 and all variable values and
units are shown in Table 2.
Table 1. State equations of the system
Variable name
State equation
Current
L · ˙
I = V in − K v · ˙
θ − R m · I
Angular position
˙
θ = d θ
dt
Angular velocity
J · ¨
θ = K t · I − B · ˙
θ − sign(θ) · τ ext
Neuron 1 activation
C m · ˙
U 1 = − G m · U 1 + G syn (U 2 ) ·
E syn − U 1
+ G Na
· m ∞ (U 1 ) · h 1 · (E Na − U 1 ) + I app
+ I pert + G fb,1 (θ) ·
E fb − U 1
Neuron 2 activation
C m · ˙
U 2 = −G m · U 2 + G syn (U 1 ) ·
E syn − U 2
+ G Na
· m ∞ (U 2 ) · h 2 · (E Na − U 2 ) + I app
+ G fb,2 (θ) ·
E fb − U 2
Neuron 1 Sdium Channel
inactivation
˙
h 1 =
h ∞ (U 1 ) − h 1
τ h (U 1 )
Neuron 2 Sodium Channel
inactivation
˙
h 2 =
h ∞ (U 2 ) − h 2
τ h (U 2 )