

4 The Analysis of Event-Related Potentials
63
¯
S COV
¯
X
, ¯
T COV
¯
X
T
.
(4.9)
The quantities in (4.8) and (4.9) are very different; in fact S and T hold the
covariance of all EEG processes that are active during the sweeps, regardless the fact
they are time and phase-locked or not, while in ¯
S and ¯
T the non-phase-locked signals
have been attenuated by computing the ensemble average in the time domain. That is
to say, referring to model (4.1), S and T contain the covariance of the signal plus the
covariance of the noise, whereas ¯
S and ¯
T contain the covariance of the signal plus
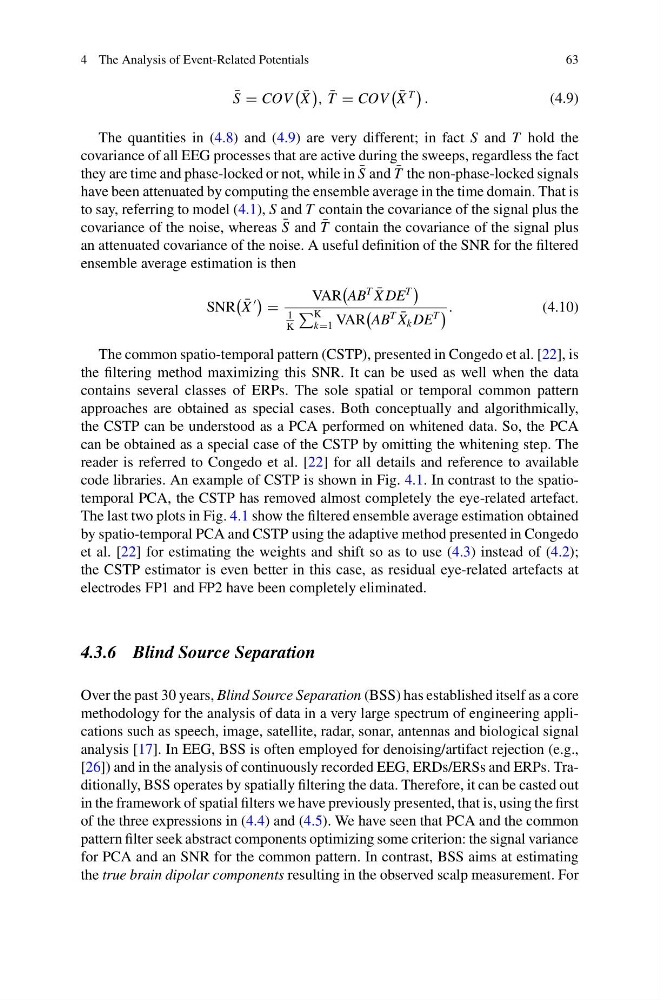
an attenuated covariance of the noise. A useful definition of the SNR for the filtered
ensemble average estimation is then
SNR
¯
X
VAR
AB
T ¯
X DE
T
1
K
K
k1 VAR
AB
T ¯
X k DE
T
.
(4.10)
The common spatio-temporal pattern (CSTP), presented in Congedo et al. [22], is
the filtering method maximizing this SNR. It can be used as well when the data
contains several classes of ERPs. The sole spatial or temporal common pattern
approaches are obtained as special cases. Both conceptually and algorithmically,
the CSTP can be understood as a PCA performed on whitened data. So, the PCA
can be obtained as a special case of the CSTP by omitting the whitening step. The
reader is referred to Congedo et al. [22] for all details and reference to available
code libraries. An example of CSTP is shown in Fig. 4.1. In contrast to the spatiotemporal PCA, the CSTP has removed almost completely the eye-related artefact.
The last two plots in Fig. 4.1 show the filtered ensemble average estimation obtained
by spatio-temporal PCA and CSTP using the adaptive method presented in Congedo
et al. [22] for estimating the weights and shift so as to use (4.3) instead of (4.2);
the CSTP estimator is even better in this case, as residual eye-related artefacts at
electrodes FP1 and FP2 have been completely eliminated.
4.3.6 Blind Source Separation
Over the past 30 years, Blind Source Separation (BSS) has established itself as a core
methodology for the analysis of data in a very large spectrum of engineering applications such as speech, image, satellite, radar, sonar, antennas and biological signal
analysis [17]. In EEG, BSS is often employed for denoising/artifact rejection (e.g.,
[26]) and in the analysis of continuously recorded EEG, ERDs/ERSs and ERPs. Traditionally, BSS operates by spatially filtering the data. Therefore, it can be casted out
in the framework of spatial filters we have previously presented, that is, using the first
of the three expressions in (4.4) and (4.5). We have seen that PCA and the common
pattern filter seek abstract components optimizing some criterion: the signal variance
for PCA and an SNR for the common pattern. In contrast, BSS aims at estimating
the true brain dipolar components resulting in the observed scalp measurement. For