

390
CHAPTER 7. LABORATORY WAVE GENERATION
designated location at the same time, i.e., the shorter waves are generated
first followed by longer waves which travel faster.
An early application of this concept was reported by Funke and Mansard
(1979a). They generated episodic breaking waves using a variation of the
“sweep frequency” technique. An irregular wave train was defined with each
successive wave having a longer period. Individual zero-up crossing wave
periods were specified, and a calculation was made to determine where all
the waves would coincide. The method may require empirical adjustment
to achieve the desired result. Mansard and Funke (1982) commented that
the sweep frequency method provides control over the location of breaking
waves, but the transient wave form cannot be specified using this method.
They also pointed out that waves may break due to critical wave steepness
which might occur before all the individual waves became superimposed.
Mansard and Funke (1982) presented a first-order method for generating
transient wave groups having an arbitrary number of waves with arbitrary
steepness. In their method, a transient wave group is constructed mathematically as a given number of uniform saw-tooth waves modulated by a
bell-shaped function. Changing the characteristics of the component waves
allowed control over the form of the resultant transient wave group. The
mathematical function describing the wave group is then Fourier transformed, and the linear dispersion relationship is used to phase-shift the
discrete frequency phase spectrum components back to the location of the
wave board. Finally, appropriate transfer functions are applied to convert
the spectrum into a wave board spectrum, and ultimately, to produce a
time series of voltages to drive the hydraulic wave board.
Mansard and Funke (1982) generated several different transient wave
groups in the laboratory, and compared them to the desired transients.
Comparisons were reasonable, but Mansard and Funke suggested that improvements could be made by incorporating nonlinear wave dispersion and
second-order wavemaker theory. Depending on the particular experiment,
application of this method may involve some trial-and-error modifications.
Synolakis (1990) presented a numerical method for determining the
wave board displacement necessary to generate transient long waves of
finite amplitude and arbitrary form at a specified location in the wave tank.
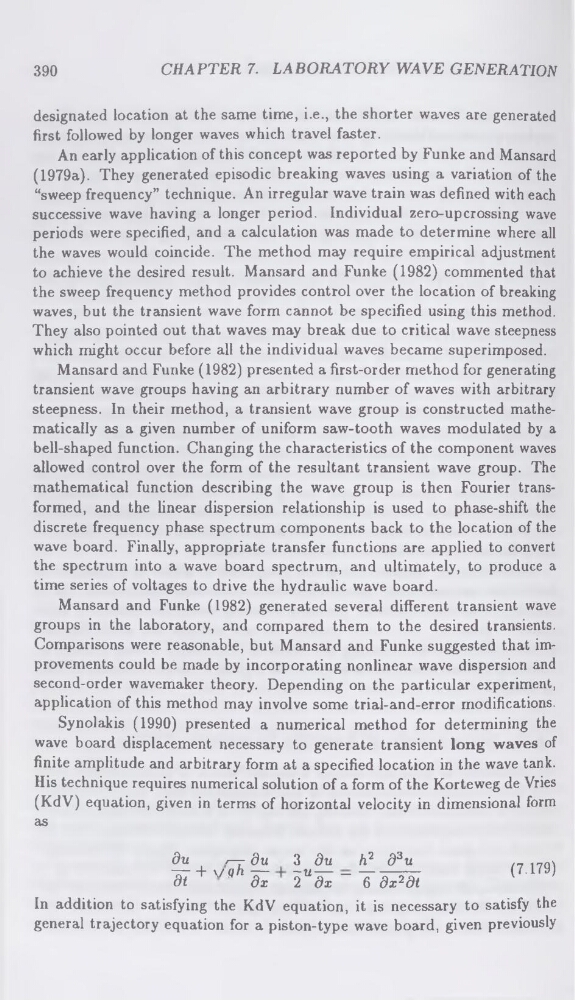
His technique requires numerical solution of a form of the Korteweg de Vries
(KdV) equation, given in terms of horizontal velocity in dimensional form
as
du
/— du
3 du
h2 d3u
17Qx
~~—I- \j q h — — u — —----------(7.179)
dt
dx
2 dx
6 dx2dt
In addition to satisfying the KdV equation, it is necessary to satisfy the
general trajectory equation for a piston-type wave board, given previously