

382
CHAPTER 7. LABORATORY WAVE GENERATION
and Synolakis attributed this success to the relatively short length of the
wave generation region.
Generally, the implicit Eqn. 7.153 will require numerical integration at
each time increment. Goring and Raichlen (1980) recast Eqn. 7.153 into an
iterative equation (containing the integral) that can be solved for 0. Once
0 is known for a particular time, the wave board displacement is calculated
from Eqn. 7.147 as
0
Xo = Ct-~
(7.154)
Alternately, Synolakis (1990) recommended integrating Eqn. 7.145 directly using the Runge-Kutta numerical integration method. He stated this
technique converges faster, particularly for cnoidal waves.
Solitary Waves
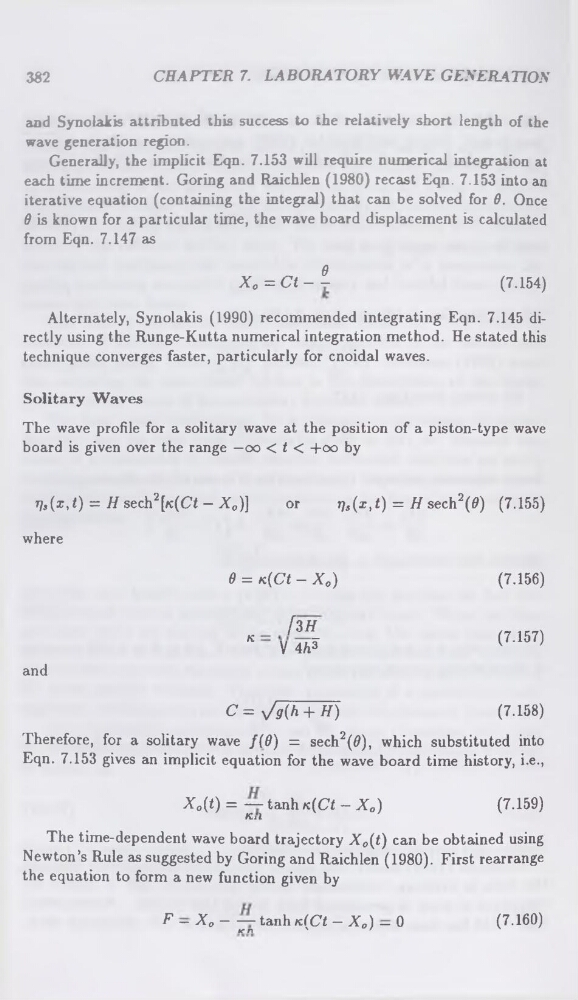
The wave profile for a solitary wave at the position of a piston-type wave
board is given over the range —oo < t < +oo by
7/3(x,t) = H sech2[/c(Ct — Xo)]
or
r)s(x, t) = H sech2(0) (7.155)
where
0 = K,(Ct — Xo)
[3H
K\4hi
and
C= \A(fi + H)
(7.156)
(7.157)
(7.158)
Therefore, for a solitary wave f(0) = sech2(0), which substituted into
Eqn. 7.153 gives an implicit equation for the wave board time history, i.e.,
X0(Z) = —- tanh K.(Ct — Xo)
Kil
(7.159)
The time-dependent wave board trajectory X0(i) can be obtained using
Newton’s Rule as suggested by Goring and Raichlen (1980). First rearrange
the equation to form a new function given by
F — Xo------ tanh /dCt — Xo) — 0
ten
'
'
(7.160)