

184
STATISTICAL RESPONSES FOR LINEAR STRUCTURES
excitation. The theory is freely drawn from the expositions of Bryson and Hu
(1975), Lin (1967), and Hedrick (1984).
State Variable Form
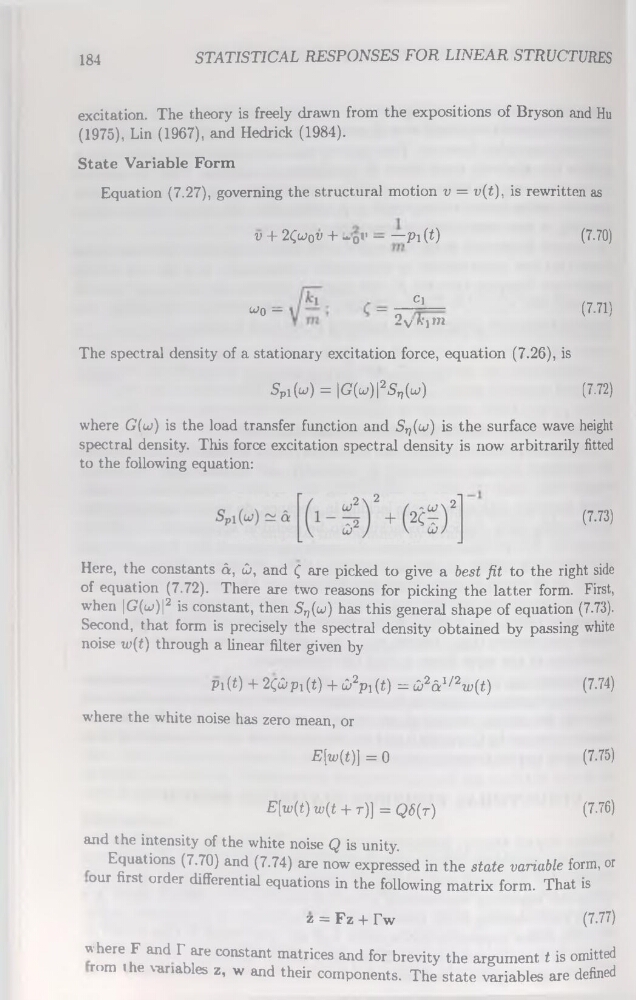
Equation (7.27), governing the structural motion v = v(t), is rewritten as
v + 2ot' + -o’’ — — Pi(^)
(7.70)
WQ —
C]
2 v ^‘1 m
(7.71)
The spectral density of a stationary excitation force, équation (7.26), is
Spl(o,) = |G(W) |2S„(W)
(7.72)
where G(w) is the load transfer function and Sv(iv) is the surface wave height
spectral density. This force excitation spectral density is now arbitrarily fitted
to the following équation:
(7.73)
Here, the constants ô, û, and Ç are picked to give a best fit to the right side
of équation (7.72). There are two reasons for picking the latter form. First,
when |G(w)|2 is constant, then Sr](u>') has this general shape of équation (7.73).
Second, that form is precisely the spectral density obtained by passing white
noise w(t) through a linear filter given by
Pi(«)+2ÇÔ;p1(t)+û2p1(t) =û2à1/2w(i)
(7-74)
where the white noise has zéro mean, or
E[w(t)] = 0
(7.75)
E[w(t)w(t + r)] =QÔ(t)
(7.76)
and the intensity of the white noise Q is unity.
Equations (7.70) and (7.74) are now expressed in the state variable form, or
our first order different ial équations in the following matrix form. That is
z = Fz 4- fw
(7.77)
w here F and T are constant matrices and for brevity the argument t is omitted
rom i he variables z, w and their components. The state variables are defined