

124
SINGLE DEGREE OF FREEDOM STRUCTURES
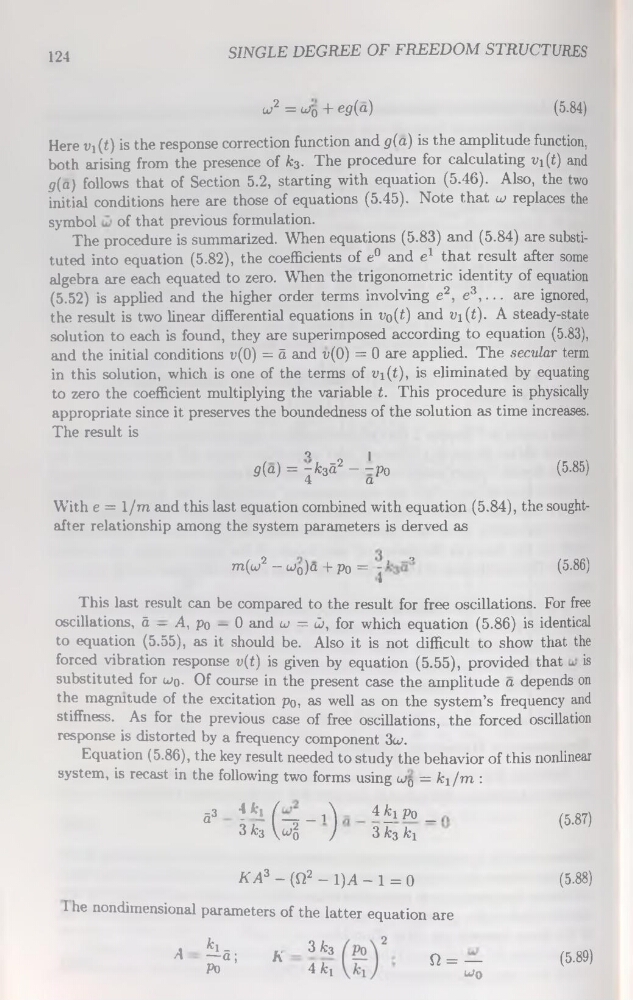
w2 = cJq + eP(a)
(5.84)
Here vj(t) is the response correction function and g(a) is the amplitude function,
both arising from the presence of k3. The procedure for calculating n(i) and
g(a) follows that of Section 5.2, starting with équation (5.46). Also, the two
initial conditions here are those of équations (5.45). Note that üj replaces the
Symbol of that previous formulation.
The procedure is summarized. When équations (5.83) and (5.84) are substituted into équation (5.82), the coefficients of e° and e1 that resuit after some
algebra are each equated to zéro. When the trigonométrie identity of équation
(5.52) is applied and the higher order terms involving e2, e3,... are ignored,
the resuit is two linear differential équations in i»o(t) and ^i(i). A steady-state
solution to each is found, they are superimposed according to équation (5.83),
and the initial conditions v(0) = â and v(0) = 0 are applied. The secular term
in this solution, which is one of the terms of vi(t), is eliminated by equating
to zéro the coefficient multiplying the variable t. This procedure is physically
appropriate since it préserves the boundedness of the solution as time increases.
The resuit is
9
|
g(a) = -k^â2 - -p0
(5.85)
4
a
W’ith e = 1/m and this last équation combined with équation (5.84), the soughtafter relationship among the System parameters is derved as
m(w2
,
_o
-u;0)a +p0 = j
(5.86)
This last resuit can be compared to the resuit for free oscillations. For free
oscillations, â — A, po — 0 and cj = ù, for which équation (5.86) is identical
to équation (5.55), as it should be. Also it is not difficult to show that the
forced vibration response v(t) is given by équation (5.55), provided that is
substituted for wq. Of course in the présent case the amplitude a dépends on
the magnitude of the excitation po, as well as on the system’s frequency and
stiffness. As for the previous case of free oscillations, the forced oscillation
response is distorted by a frequency component 3w.
Equation (5.86), the key resuit needed to study the behavior of this nonlinear
System, is recast in the following two forms using Wq = ki/m :
û3 âh
3 fc3
4^iPo _
3 k$ ki
(5.87)
K A3 - (fi2 - 1)A - 1 = 0
(5.88)
(5.89)
I he nondimensional parameters of the latter équation are
•
ki _
A
—a ;
Po
A
3 k3
4 ki
Wo
Q = —