

smoothing effect is achieved, because the intensity of the pixels within the window
is now replaced by an average value.
Median filtering results in a similar effect. The filtering process works in the
same way as average filtering. The difference lies in the fact that the centre pixel of
the filtering window is replaced by the median or middle value of the surrounding
pixels. The disadvantage of the average and median filters is their insensitivity to
edges and their tendency to smooth out areas of interest. In order to avoid these
shortcomings, other filters, such as the variance filter or the convex hull filter, may
be applied.
The variance filter uses a process from which the intensity value of the centre
pixel of the filter window is replaced by the statistical standard deviation of the
surrounding pixel values. Variance filtering is therefore more sensitive to abrupt
changes in image intensity values. It achieves a smoothing effect while still
preserving most of the sharp changes.
The convex hull filter is a geometric filter. It evaluates the intensities of neighboring pixels within a filtering window in a three-dimensional space. The result of
the smoothing operation is reduced small-scale intensity variation as it occurs in
speckle, and it preserved intensity variation of large-scale image features.
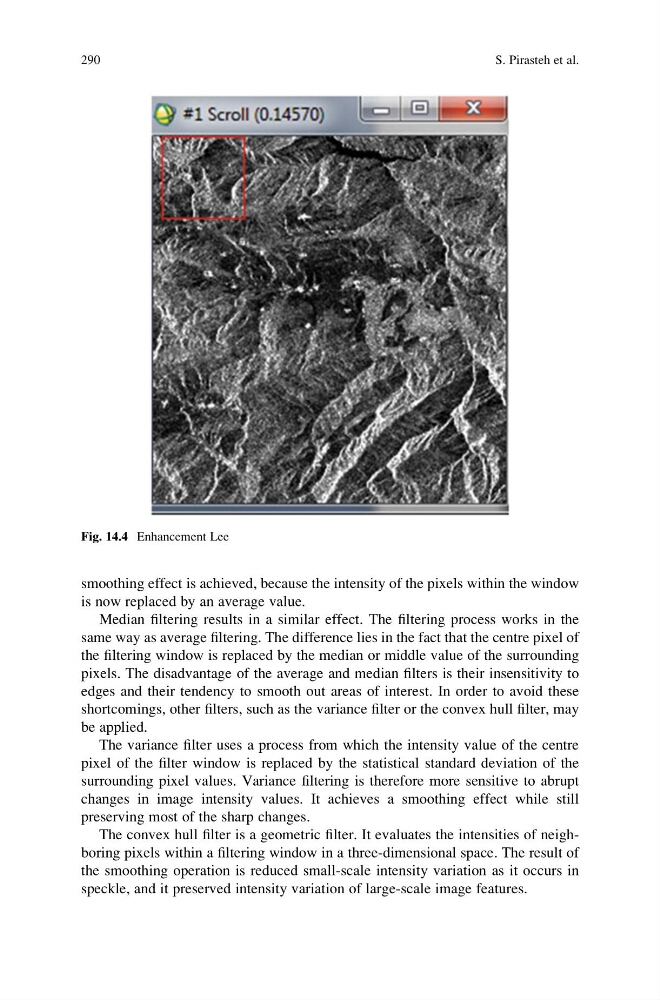
Fig. 14.4 Enhancement Lee
290
S. Pirasteh et al.