

240
C. Noël et al.
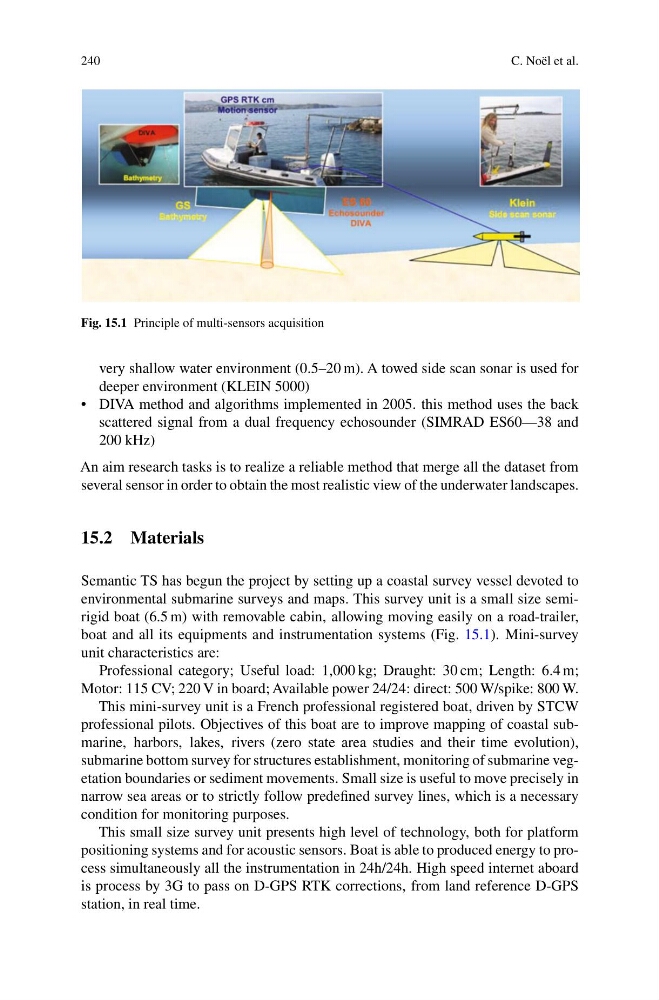
Fig. 15.1 Principle of multi-sensors acquisition
very shallow water environment (0.5–20 m). A towed side scan sonar is used for
deeper environment (KLEIN 5000)
• DIVA method and algorithms implemented in 2005. this method uses the back
scattered signal from a dual frequency echosounder (SIMRAD ES60—38 and
200 kHz)
An aim research tasks is to realize a reliable method that merge all the dataset from
several sensor in order to obtain the most realistic view of the underwater landscapes.
15.2 Materials
Semantic TS has begun the project by setting up a coastal survey vessel devoted to
environmental submarine surveys and maps. This survey unit is a small size semirigid boat (6.5 m) with removable cabin, allowing moving easily on a road-trailer,
boat and all its equipments and instrumentation systems (Fig. 15.1). Mini-survey
unit characteristics are:
Professional category; Useful load: 1,000 kg; Draught: 30 cm; Length: 6.4 m;
Motor: 115 CV; 220 V in board; Available power 24/24: direct: 500 W/spike: 800 W.
This mini-survey unit is a French professional registered boat, driven by STCW
professional pilots. Objectives of this boat are to improve mapping of coastal submarine, harbors, lakes, rivers (zero state area studies and their time evolution),
submarine bottom survey for structures establishment, monitoring of submarine vegetation boundaries or sediment movements. Small size is useful to move precisely in
narrow sea areas or to strictly follow predefined survey lines, which is a necessary
condition for monitoring purposes.
This small size survey unit presents high level of technology, both for platform
positioning systems and for acoustic sensors. Boat is able to produced energy to process simultaneously all the instrumentation in 24h/24h. High speed internet aboard
is process by 3G to pass on D-GPS RTK corrections, from land reference D-GPS
station, in real time.