

Optimization in Cellular Automata
203
Lagrangian (1,) with the transition probabilities occur. The mean trajectory
t
corresponds to the minimum of the functional A ~ f Ldt; the probato
bility for small derivations from the mean trajectory has a Gaussian form.
N on-linearities create a sort of potential energy with many stable varieties
Xi diverting the trajecton' from its influence zone iIi' At a shift normal to
Xi a minimum of L occurs. For closed Xi the motion on it could be quasiergodic, for open Xi it is to be separated into a longitudinal part Xl (t)
and a transversal quasi-random one xlr (t). It is the effective Lagrangian,
precised by the anisotropic part of the transition probabilities, which
determines X,; pla\ing at the same time the role of a transversal negentropy.
If the deviations from Xi exceed the distance between neighbouring
varieties then the "kinetic" energy allows to surmount the potential
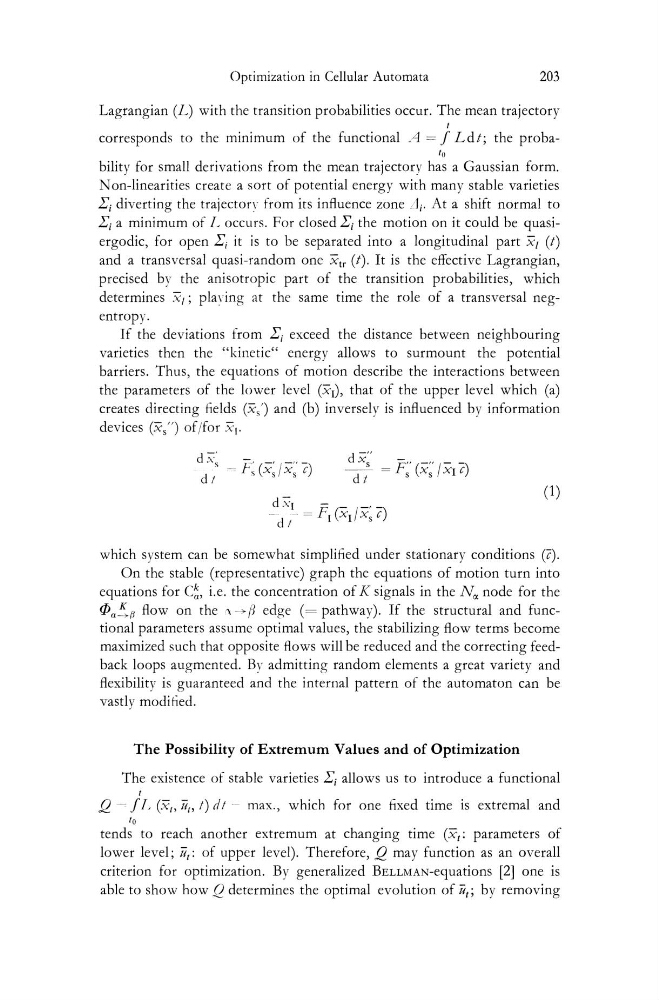
barriers. Thus, the equations of motion describe the interactions between
the parameters of the lower level (XI)' that of the upper level which (a)
creates directing fields (xs') and (b) inverselv is influenced by information
devices (xs") of/for X,.
d;::' s
elt
(1)
which system can be somewhat simplified under stationary conditions (c).
On the stable (representative) graph the equations of motion turn into
equations for C~, i.e. the concentration of K signals in the Nrx node for the
(/) a-K,.fj flow on the"·,, /i edge (= pathway). If the structural and functional parameters assume optimal values, the stabilizing flow terms become
maximized such that opposite flows will be reduced and the correcting feedback loops augmented. By admitting random elements a great variety and
flexibility is guaranteed and the internal pattern of the automaton can be
vastly modified.
The Possibility of Extremum Values and of Optimization
The existence of stable varieties Xi allows us to introduce a functional
t
Q fT, (x/> til' I) dl max" which for one fixed time is extremal and
to
tends to reach another extremum at changing time (x t : parameters of
lower level; tit: of upper level). Therefore, Q may function as an overall
criterion for optimization. By generalized BELLMAN-equations [2] one is
able to show how Q determines the optimal evolution of tit; by removing