

374
J. Murawski and J. Woge Nielsen
described in Chap. 3. Based on it, the geographical position and extent of the spill,
the amount of shoreline or bottom contamination, toxic levels, slick layer thickness,
etc., may be derived.
In the forecast mode, an oil drift simulation is a valuable decision tool for spill
response: how, when and where to combat a spill and thereby reduce the environmental impact. In scenario studies, drift simulations are a tool for risk analysis and
assessment.
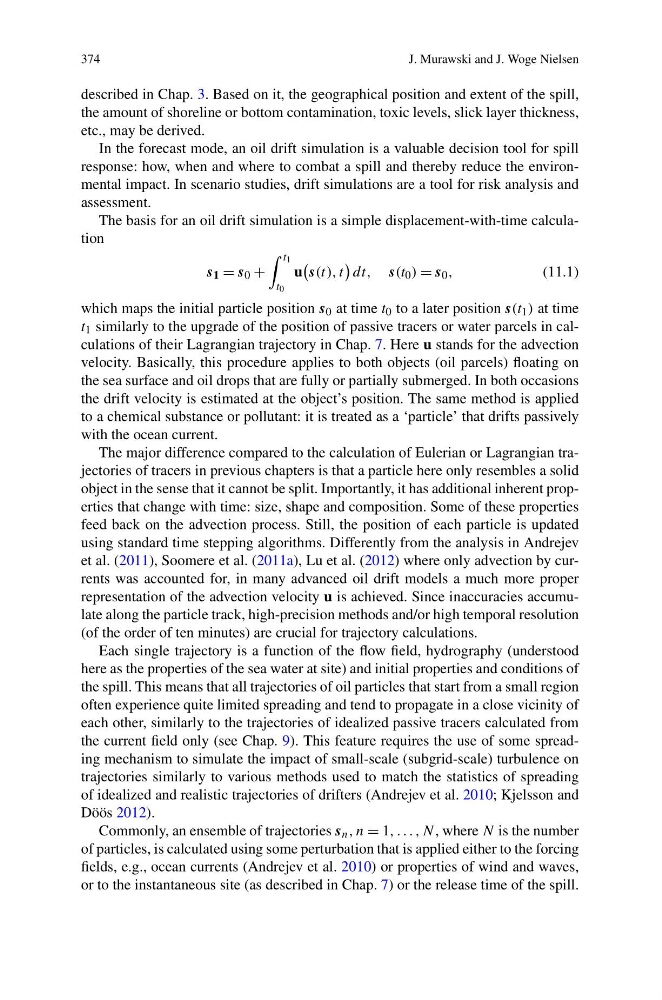
The basis for an oil drift simulation is a simple displacement-with-time calculation
s 1 = s 0 +
t 1
t 0
u
s(t), t
dt, s(t 0 ) = s 0 ,
(11.1)
which maps the initial particle position s 0 at time t 0 to a later position s(t 1 ) at time
t 1 similarly to the upgrade of the position of passive tracers or water parcels in calculations of their Lagrangian trajectory in Chap. 7. Here u stands for the advection
velocity. Basically, this procedure applies to both objects (oil parcels) floating on
the sea surface and oil drops that are fully or partially submerged. In both occasions
the drift velocity is estimated at the object’s position. The same method is applied
to a chemical substance or pollutant: it is treated as a ‘particle’ that drifts passively
with the ocean current.
The major difference compared to the calculation of Eulerian or Lagrangian trajectories of tracers in previous chapters is that a particle here only resembles a solid
object in the sense that it cannot be split. Importantly, it has additional inherent properties that change with time: size, shape and composition. Some of these properties
feed back on the advection process. Still, the position of each particle is updated
using standard time stepping algorithms. Differently from the analysis in Andrejev
et al. (2011), Soomere et al. (2011a), Lu et al. (2012) where only advection by currents was accounted for, in many advanced oil drift models a much more proper
representation of the advection velocity u is achieved. Since inaccuracies accumulate along the particle track, high-precision methods and/or high temporal resolution
(of the order of ten minutes) are crucial for trajectory calculations.
Each single trajectory is a function of the flow field, hydrography (understood
here as the properties of the sea water at site) and initial properties and conditions of
the spill. This means that all trajectories of oil particles that start from a small region
often experience quite limited spreading and tend to propagate in a close vicinity of
each other, similarly to the trajectories of idealized passive tracers calculated from
the current field only (see Chap. 9). This feature requires the use of some spreading mechanism to simulate the impact of small-scale (subgrid-scale) turbulence on
trajectories similarly to various methods used to match the statistics of spreading
of idealized and realistic trajectories of drifters (Andrejev et al. 2010; Kjelsson and
Döös 2012).
Commonly, an ensemble of trajectories s n , n = 1, . . . , N, where N is the number
of particles, is calculated using some perturbation that is applied either to the forcing
fields, e.g., ocean currents (Andrejev et al. 2010) or properties of wind and waves,
or to the instantaneous site (as described in Chap. 7) or the release time of the spill.