

11 O Geir Evensen
EKF: Estimate
20
15
10
~
5
•
O
~
~
·5
WIW
· 10
·15
·20
O
5
10
15
20
25
30
35
40
timeI
EKF: rror vari ance
30
25
20
15
10
5
5
10
15
20
25
30
35
40
[imei
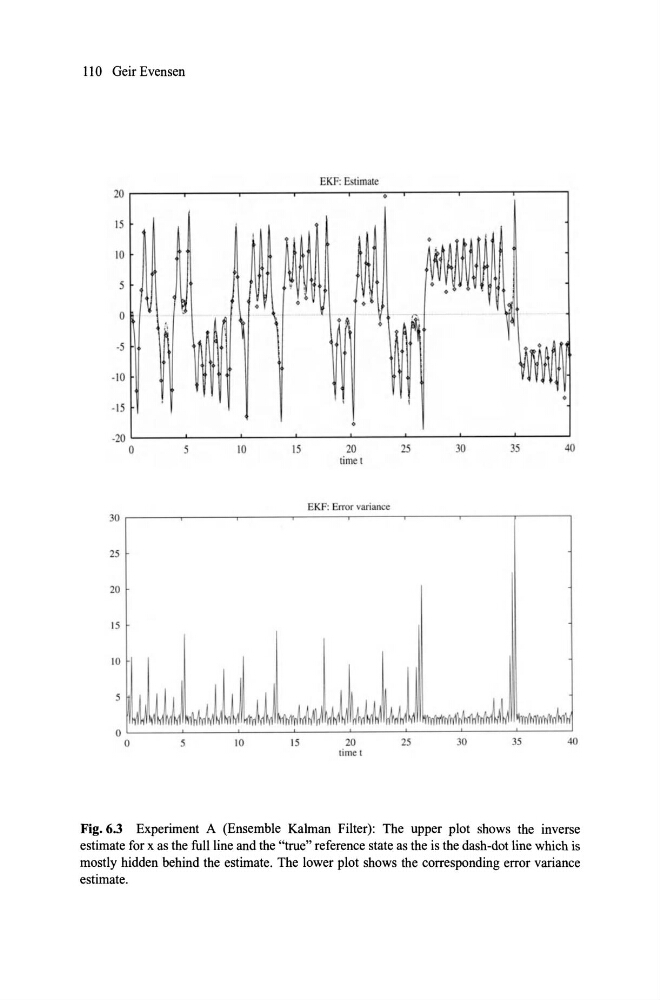
Fig.6.3 Experiment A (Ensemble Kalman Filter): The upper plot shows the inverse
estimate for x as the fulliine and the "true" reference state as the is the dash-dot line which is
mostly hidden behind the estimate. The lower plot shows the corresponding error variance
estimate.